Advanced Tutorial: Square Packing, Search, and Proof
- Human oversight: Levy
- Agents: Opus 5, Fable 5, Fable 5.1, Opus 5.5, and GPT-6 Astra
- First published October 14, 2026 · Last revised October 15, 2026
A packing certificate answers whether a specified arrangement fits. An optimality proof must also exclude every smaller arrangement, including ones no search has found. That distinction determines the mathematics: linear programs refine one separation pattern, exact arithmetic decides a construction, and global proofs combine complete covers, exclusions, capture and local geometry.
The basic tutorial defines the problem and develops the first examples. Here is the least side of a square containing independently rotatable unit squares with disjoint interiors; contact is allowed. The elementary bounds are , and equality holds at square counts. The sections below develop the methods, retaining their assumptions, examples and limits. The vocabulary and notation tables collect the definitions.
Evidence date: 14 October 2026. The results register and case records own current claims and statuses. Search measurements remain tied to their cited experiments. In particular, a later proof of an optimum does not validate an earlier search strategy, and an intake review does not adopt a bound. Epistemics owns the evidence and credit rules.
1. Configuration Space and Linear Programs
A configuration places every square and fixes the container. Square has a centre and an angle , and the container has side . Angles stop at because a unit square is unchanged by a quarter turn, so larger angles name poses already counted.
Throughout, a subscript picks out one square and a bare letter is the whole -vector: is all angles at once, and and are the centre coordinates each. So “fix the angles” always means fix all of them. Counting scalars, a configuration is real numbers—34 at . §10 collects every symbol used in this document.
Read naively, this is a 34-dimensional nonconvex problem with disjunctive constraints, and it is not obvious where to push. Fixing the discrete separation choices and the angles separates a tractable subproblem from the remaining search.
The cell decomposition
Two convex polygons have disjoint interiors exactly when some line separates them, weakly—touching is allowed, and the separating line may run along the shared edge. For polygons it suffices to test lines parallel to their edges. A square has two distinct edge normals, since opposite edges are parallel, so each pair of squares has four candidate axes, and for each axis a choice of which square lies on the low side.
A cell of configuration space is a choice, for each of the pairs, of one candidate separating axis together with an order. A configuration lies in a cell when those choices genuinely separate those pairs in that order.
Four axes times two orders is eight choices per pair, so there are at most cells—about at . Most are empty, because the choices must be jointly realisable by an actual configuration, but even as a crude bound the number says what kind of difficulty the discrete half carries.
Now fix the angle vector and fix a cell. Write for rotation by , so the four corners of square are , and write for those four corner offsets, . Four things become true at once:
- Once is fixed, the offsets are constants, so every corner is an affine function of the centre alone.
- Containment is linear: each corner satisfies and , writing and for the two components of . Note appears here, and only here, as a variable.
- Separation along a fixed axis is a linear inequality. For axis and the order before , every corner of projects at or before every corner of : for all . Because the cell fixes both and the order, there is no absolute value and no case split left.
- The objective is itself, which is linear.
So the whole problem, restricted to one cell at fixed angles, is
minimise    s
over        x₁…xₙ, y₁…yₙ, s          (2n + 1 variables; 23 at n = 11)
subject to  0 ≤ xᵢ + oᵢₖ,ₓ ≤ s       for every square i and corner k
            0 ≤ yᵢ + oᵢₖ,ᵧ ≤ s
            ⟨ν_ij, (xᵢ,yᵢ) + oᵢₖ⟩ ≤ ⟨ν_ij, (xⱼ,yⱼ) + oⱼₗ⟩   for every pair (i,j)
with every and every axis a constant, determined by and the cell. That is the result the synopsis calls T-2.
A linear program minimises a linear objective over linear inequalities.
Its feasible region is a polyhedron.
For the feasible packing LP above, whose finite optimum is attained and whose feasible
region has vertices, one can choose an optimum at a vertex.
The class is solvable in polynomial time and is fast in practice; representative project
solves took about 1.28 ms in the
recorded infrastructure benchmark.
Two further properties matter later.
The set of constraints holding with equality at the optimum is its active set, and
the corresponding optimal basis is the subset of them the solver uses to pin the
vertex down; §2 turns entirely on what happens when that basis changes.
And a linear program can be solved exactly over rational coefficients, which is why
the floating-point floor in §3 is a limit of
the implementation rather than of the mathematics.
§11 points to a proper treatment.
The solver this project actually calls is HiGHS, an open-source high-performance linear and mixed-integer optimizer, reached through SciPy. It works in floating point, so it does not return the exact optimum of the cell it is given—it returns one within a declared feasibility tolerance, the margin by which a returned solution is allowed to violate its own constraints. That tolerance is where the floor in §8 comes from, and setting it too loosely once produced a packing that violated its own separation constraint, and so a side below the standing record.
The remaining nonconvexity lies in two places: the trigonometric dependence of the offsets and axes on the angles, and the discrete choice of cell. That factorization separates the angular optimization from the combinatorial search over cells.
The two independent formulations use different constraint assemblies but describe the
same feasible set. sqpack.research.quench uses one separation row per pair;
cases.trump11.independent_lp_cell uses sixteen, one per ordered corner pair, for
rows at . They share no constraint-assembly
code.
The check that makes it concrete: read the cell off the exact certificate for the best known packing (eleven angles and fifty-five axis choices, and nothing else), rebuild the linear program from scratch, and solve it. The centres are never given to the solver—they are what it reconstructs. It returns the published side to and every centre to .
Trump’s exact construction has 14 touching pairs among its 55 pairs and 20 corner coordinates exactly on container walls. The independent reconstruction checks the geometry, while a drawing only displays it. Contact equality is why the exact representation in §3 matters.
Thirty-four dimensions become one
An angle class is a set of squares constrained to share one angle. Trump’s packing uses only two: six squares at , and five sharing a single oblique angle. Call that shared angle , so the full angle vector is up to relabelling—one free number in place of eleven.
Hold the cell fixed, vary , and solve the linear program of the previous section at each value. That defines a function of one real variable,
φ(a) = the optimal side s of Trump's cell, with the five tilted squares at angle a
so , and it is the entire problem restricted to this
cell. Write for the angle that minimises it.
A * marks a distinguished value of a symbol rather than one fixed relation:
is a minimiser, and in §5 is the standing
best for an , which is not known to be a minimum in the open cases.
A 2,001-point scan of independently puts the lowest grid
sample within one step of Trump’s published tilt and locates the neighbourhood of the
minimiser .
Trump’s angle is not an input to that computation. It is the argument that minimises a one-dimensional function anyone can plot. In this particular structured cell, the centres remain LP variables and only one nonlinear angle parameter remains. This is evidence that angle-class models can compress record cells dramatically; it is not a theorem that class count equals the local dimension of the full packing problem. Other records already use more classes—six, numerically, at —and every proposed compression must be checked on its own contact structure.
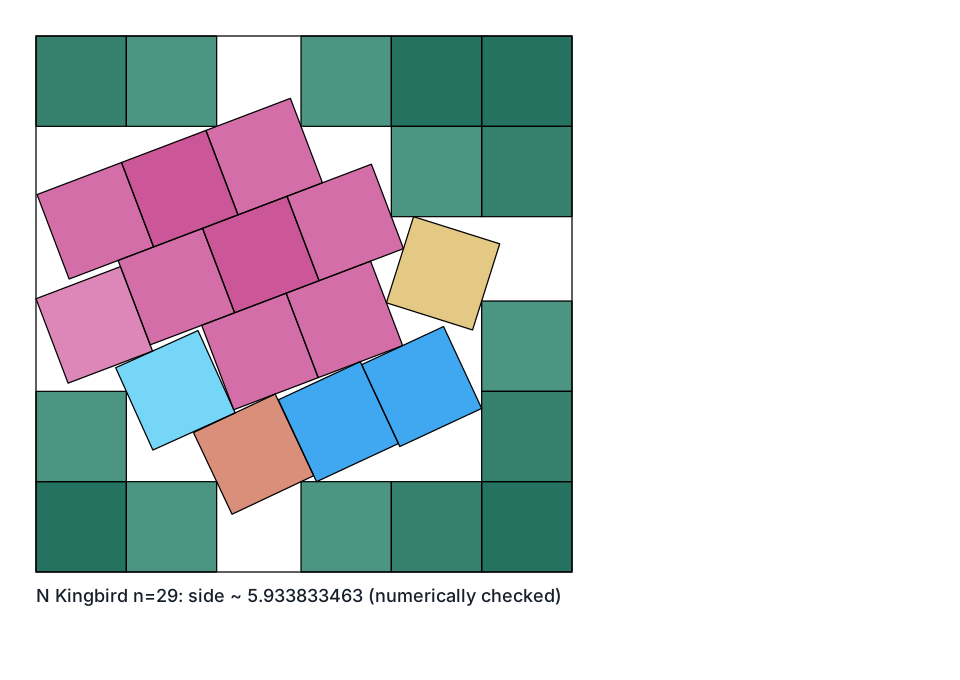
The reported n = 29 record is a useful larger-scale check: six orientation classes
across 29 squares. The retained roughly 100-digit source is evaluated at 160 decimal
digits of working precision and passes all 406 pair checks at tolerance 1e-80; that
numerically checks that source transcription without making it an exact certificate or
an optimality proof.
The later T-009 interval certificate and T-155 rational certificate are separate
evidence objects; the latter is discussed in
regularization.
2. Refinement, Corners, and Connected Families
The retained experiments distinguish three objects: a separation cell, a numerical refiner’s endpoint, and a connected component of mathematical local optima.
The quench map
Borrowed from Stillinger and Weber’s inherent structure decomposition: the quench map sends a configuration to the pose that a deterministic refinement returns. A basin, or point-basin where the distinction matters, is the preimage of one returned pose. The atlas ultimately wants a coarser, mathematically stable relation on connected terminal components; the current point keys do not yet provide it.
A quench map is a general notion; this project uses one particular algorithm, and the specifics matter for what follows. It has two nested loops, not one.
The inner loop makes the side a function of the angles. Given a pose, the cell is read off it: for each pair, take the candidate axis of greatest separation, together with the sign saying which square is low. That cell defines the linear program of §1, which is solved in the centre-and-side variables. But the solution may lie in a different cell from the one it was solved in, so its value is an upper bound that depends on where the caller started. That path dependence would make ill-defined and leave any angle search optimising a moving target. So the loop re-reads the cell from the solution and re-solves until the cell it reads back is the cell it was given—a cell fixed point. It can also stop unsettled, with a typed reason, and an unsettled result is exploratory data rather than a converged endpoint.
The outer loop moves the angles. It works one angle class at a time, minimising each by golden-section bracketing inside a window that narrows only when a whole sweep fails to improve. No derivative is used—deliberately, for the reason §2 gives. A final optional pass brackets each of the angles individually, to test whether a class-converged pose is genuinely stationary or an artifact of the tolerance that decided which angles count as one class. The sweeps stop when none improves, or a tolerance, sweep cap, or wall-clock budget is reached.
So: read the cell, solve to a cell fixed point, bracket the angle classes, repeat.
The knobs are real—a class-merge tolerance, a window schedule, budgets—and that is exactly why a basin defined by this map inherits them. It is also why the free-angle pass exists. Note too that changing the refiner changes the map, and therefore changes what “basin” refers to: swapping angle descent for class bracketing, which §2 does, is a different quench and a different decomposition.
Two derived words carry the project’s central diagnostic:
- Polish: refinement within the basin you are already in. This is what the quench does, and all it does.
- Exploration: reaching a different basin. The retained early annealing experiments did not do this reliably at .
A gap therefore decomposes into a polish failure (right region, weak refinement) or an exploration failure (wrong region, and refinement cannot help). Which one a number represents cannot be read off the number; you establish it by running the refiner and seeing whether the gap moves.
Trap 1—a fixed-angle cell solve is not a basin
A cell fixes only the discrete separating axes and orders. The fixed-angle LP subproblem fixes both a cell and an angle vector; a basin does neither, because the quench may change angles and cross cells. A configuration can therefore sit at exactly its fixed-angle cell optimum and still be far from its quench endpoint, with all the remaining gap in the angles and none in the centres.
A fixed-angle solve that stops improving has exhausted only the variables it may move; it has not converged to a local optimum of the full problem. Watching it flatten and concluding “wrong basin” is exactly what the right basin looks like when the residual is angular.
On one start, the annealer output and the fixed-angle solve agree to every digit at , while the full quench with its angle half reaches (D-029).
The renderer guide retains the shared-scale Göbel source-return diagnostic: the start is close but not settled, while the full quench returns to the proved-side geometry.
Trap 2—a point-basin need not be a terminal component
A deterministic quench still returns an individual pose. The problem is that its local optimum can lie on a connected terminal family, so point-preimages split the component-level object the programme actually wants to count.
At the exact side-2 optimum contains a connected sliding family: centres , , and for . One connected optimal component, infinitely many distinct coordinate keys. The quench lands wherever in the flat region it happened to enter, and every symptom mimics a real discovery—distinct coordinates, distinct keys, two rows in the store—while the side agrees exactly and, along the family’s open stratum, so does the contact certificate (the wall endpoints carry a different one).
The object that survives this trap has been computed exactly, and the figure below is its map. is the space of all packings of three unit squares in the side-2 container—and since is proved, that is the complete optimum space, not a sample of it. With the squares labelled, the space is two disjoint circles, each a cycle through twelve discrete states, cross-checked against the published hard-squares computation of the same space. Forgetting the labels—quotienting by the symmetric group —merges the two circles into one: relabelling was separating configurations the mathematics does not distinguish. Quotienting also by the container’s eight symmetries folds that circle to the closed interval , where is the slider parameter above with the reflection divided out. Three strata remain: the corner pose at , the generic slide, and the centred pose at .
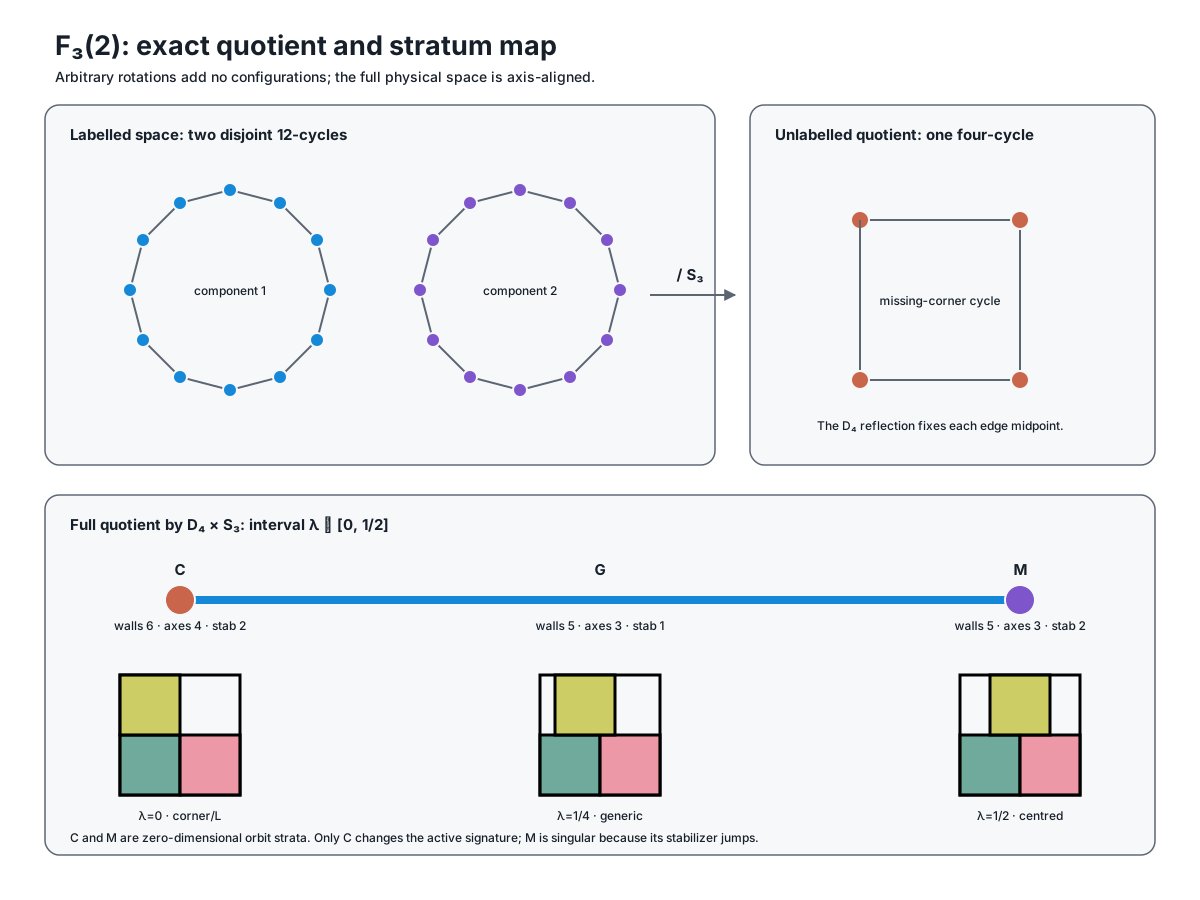
Each quotient stage kills one wrong identity—relabellings and container symmetries are not new basins—and the interval kills the rest: four exact sample poses with four distinct geometric keys, two contact signatures, and three strata are one connected component.
That is why this object is a permanent known-answer control rather than an illustration. A frozen component-assignment policy is accepted only if it recovers this interval, and the quotient point, exactly while rejecting every shortcut: exp-032 proposed geometric keys, contact signatures, finite samples, labelled states, and floating-point matches as component identities, and all seven such mutations were refused. Passing that gate is what admitted the bounded connectivity work below, and this map is the only exact ground truth behind open question 1 in §8.
At , two retained poses with different coordinate keys share an exact fixed-angle LP-optimal face after a container symmetry and relabeling (exp-033). The angle-and-slide sheet containing that face has side , above . It describes a different configuration from Göbel’s global optimum. An exact second-order obstruction rules out one proposed escape direction from that sheet; the complete nonlinear component remains unclassified (the retained account).
Göbel’s optimum has a separate result: T-012 proves that its only infinitesimal
motion, rotation of the middle square, is obstructed at second order; T-014 proves
local isolation at fixed side, both at V3/C3
(proof).
The first-order direction is therefore not an actual motion.
Neither theorem classifies every optimal five-square configuration.
The distinction between the nonoptimal sheet and the isolated optimum is essential when
using either as a control.
The project’s term for this is a terminal family. The nullity of the appropriate independent active-constraint Jacobian, after quotienting symmetries and accounting for inequalities and stratum changes, is its linearized dimension. It equals local dimension only on a regular constant-rank stratum, or after a separate integrability argument. At a singular constraint, nullity can overstate the local dimension: has Jacobian nullity one at zero but local dimension zero. Raw contact counts cannot supply even the linearized rank—contacts may be dependent, one contact description may encode several scalar conditions, and angles and cells may change along a motion. Subtracting contacts from variables is not a rigidity calculation.
Terminal components and their representation
A mathematical terminal component is independent of the search’s tolerances and the representation’s coordinate keys. A quench that merges nearby angles depends on its merge tolerance; a coordinate key can split a continuous family into distinct entries. Neither choice establishes the component’s identity.
The corner
The figures here are measurements from the retained early search campaign, not a benchmark of every current solver.
is not smooth at its minimum.
Refined finite differences give one-sided rise rates of about to the left and
to the right per radian, stable over five decades.
In the conventional signed derivative, these are about and . Two
independent LP formulations agree: /0.3839 at a ratio of , and
/0.3841 at a ratio of . The derivative does not vanish at the
optimum; it jumps.
Why. Where the LP’s optimal basis is locally constant, is smooth and its derivative reads off that basis. A corner occurs where the optimal basis switches as the angle crosses . Because a basis is only a subset of the active rows, a basis switch alone does not show that the full active-contact set changed.
Measured improvement. Replacing smooth descent with a bracketing search over merged angle classes—a method that tolerates non-smoothness—and changing nothing else took from descent’s to , and from to . Measured from the annealer output both quenches start from, that is and respectively. All four figures are medians over the five tested seeds; the worst seed stays at .
Limit of the improvement. At the same substitution moves the annealer’s only to . And it is not a theorem that derivative-free methods must fail: Powell and Nelder–Mead did worse than descent on the tested starts, in this implementation, which is method-selection evidence and not an impossibility result. The kink also lives on a one-dimensional slice, so it is not by itself a rigidity proof for the full packing.
The synopsis presents this measurement-to-method chain as a full worked example.
3. Exact Arithmetic and Reconstruction
Why exactness is not optional
Floating-point evaluation can certify a strict inequality when a sound error bound stays away from zero. It cannot infer that an unrecognised near-contact is exactly equal to zero merely because a computed residual is small.
For Trump’s algebraic coordinates rounded to f64, the current float verifier needs a tolerance to accept the true contacts. That tolerance is a blind spot that also accepts overlaps smaller than itself; setting it to zero rejects this true packing instead. Both failure modes are demonstrated by a negative control in this directory. There is no tolerance in this predicate that both accepts Trump’s rounded packing and rejects all violations, and raising precision shrinks the blind spot without turning a small residual into an equality proof.
Generic interval evaluation does not by itself fix this identification problem. An enclosure lying strictly above zero is a proof of strict separation, while a finite-width enclosure of an unrecognised near-contact normally cannot distinguish exact zero from a tiny violation. Structural simplification can produce , and certified root methods can prove existence and uniqueness of a solution satisfying contact equations. What interval evaluation alone cannot do is promote an approximate coordinate residual to an unknown exact contact. The final verifier therefore needs an exact representation or an independently certified equality system, not a contact tolerance.
The fix is therefore representational rather than numerical: work in the real algebraic number field the packing actually lives in, where equality is decidable.
One predicate, several scalar types. That fix is affordable because of a property of
the geometry: every quantity the separating-axis test evaluates is a polynomial in the
configuration variables—four candidate axes, eight dot products per axis, no divisions
and no square roots.
So a single implementation is correct over f64, over intervals, and over an exact
field; only the scalar type and the sign decision change.
The verifier here is written once and instantiated at each, which is why “work exactly”
is a choice about where to spend time rather than a second codebase.
Cost determines where to use exact arithmetic. The representative measurements below come from the infrastructure benchmark:
| Operation | Cost |
|---|---|
Separating-axis pair test, f64, compiled |
57 ns |
| The same test, Python float backend | 2,726 ns |
| One multiplication at degree 8, the field, pure Python | 215.5 µs |
| The same, with a compiled bignum backend (benchmarked; not integrated) | 1.2 µs |
| One multiplication at degree 62 | 13 ms |
| Complete exact verification of Trump’s packing, all 55 pairs | 0.35 s |
For the eleven-square benchmark, complete exact verification cost less than a second.
That timing does not describe large rational certificates or global exclusion proofs.
The cost is not flat: one exact multiplication climbs from 215.5 µs at degree 8 to
13 ms at degree 62 in pure Python, and even the compiled backend’s advantage over pure
Python grows with degree—177× at 8, 578× at 62—so exact arithmetic is most expensive
exactly where the problem is hardest.
That is the standing reason it stays out of the search loop.
The useful frame is three budgets rather than one.
An agent tier at 1–10 s per operation, where a proof or a verification lives and
nothing needs optimising; an interactive tier at 10 ms–1 s; and an inner loop at 10
ns–1 µs executed –1e12 times, for which the measured search uses f64. Screen
in floating point, refine in floating point, decide in the number field.
The number field
A real algebraic number field is what you get by adjoining one real algebraic number to the rationals. The procedure:
- Recover the field. Put the configuration in for a single primitive element , with a known minimal polynomial and an isolating interval that contains the intended real root of and no other.
- Represent elements as polynomials in of degree with rational coefficients, reduced modulo . Arithmetic is exact.
- Decide equality exactly. For an element , exactly when its reduced representative is the zero polynomial. This is where touching contacts get certified.
- Decide sign exactly—evaluate that representative on the isolating interval with rational interval arithmetic, bisecting when the enclosure straddles zero. This terminates because a nonzero representative of degree cannot vanish at , since is the minimal polynomial.
- Run separation and containment using only those two decisions. No floating point appears anywhere.
For Trump’s packing the field is with , of degree 8. A useful subtlety: , , and are all algebraic, but the angle itself, in radians, is transcendental by Lindemann–Weierstrass. The algebra lives in the trigonometric values, never in the angle.
How many roots does a packing need?
Step 1 says “a single primitive element” as though one always suffices. It does, and the reason is worth stating, because the obvious guess—that a configuration with algebraic coordinates might need many—is wrong.
One, always. By the primitive element theorem every finite extension of is simple, since characteristic zero makes every finite extension separable. So however many algebraic coordinates a packing has, each with its own degree, there is a single whose powers express all of them, and every coordinate becomes a polynomial in with rational coefficients. Only one root of is the intended one, which is why an isolating interval is part of the field data rather than an optimisation.
The field degree depends on the geometry. The primitive element theorem alone gives no useful degree estimate for this computation; the chosen contact system and its elimination determine the field that a reconstruction needs. It is 8 for Trump’s packing, and reaches 62 elsewhere in the record table. The square count alone does not specify a configuration’s field degree. For a construction with rational centers and container side, a Pythagorean tilt such as also gives rational vertex coordinates, so its coordinate field has degree one. The tilt alone does not make the centers or the container side rational. Which fields and degrees actually occur, and how they follow from the contact mechanism, is an open question in the registry rather than something known.
And the guarantee is not pointwise. The optimal side is algebraic, by a standard argument this directory does not otherwise use. The half-angle substitution turns and into rational functions of , so validity defines a semialgebraic set over with no transcendental functions anywhere. The set of achievable sides is a projection of that set, and by the Tarski–Seidenberg theorem a projection of a semialgebraic set is semialgebraic—hence a finite union of points and intervals with algebraic endpoints, whose infimum is algebraic. An individual optimal configuration need not be. Where the optimum is a positive-dimensional family, the family is cut out by polynomials but a point on it carries a free parameter: the sliding family in §2 is for , and may be transcendental.
An isolated solution of the declared rational polynomial system has algebraic coordinates. Recovering its field is therefore a meaningful target. An arbitrary point on a family may instead contain a transcendental free parameter; exact algebraic reconstruction must choose an algebraic representative or represent the family. That is the same distinction §2 draws between a point-basin and a terminal component, arrived at from the algebraic side.
Assurance, method, and precision
Never extrapolate across an assurance or arithmetic boundary.
| Assurance | What it means |
|---|---|
reported |
A named source states the claim; this project has not established it independently |
numerically-checked |
A finite calculation checked the scoped predicates under an explicit method, precision, rounding, and tolerance |
verified |
An exact check, rigorous interval certificate, or complete proof decides the claim and its preconditions |
The method is recorded separately. Witness and machine-check evidence uses four tokens:
| Method | What it is |
|---|---|
numerical-f64 |
Hardware floating point; says exactly what arithmetic was used |
numerical-multiprecision |
Higher precision, which must state the actual digits or bits and the tolerance—it does not mean unlimited precision |
interval-certified |
Rigorous interval arithmetic, which can certify a strict inequality |
exact-algebraic |
Exact replay in the packing’s own number field, where equality is decidable |
The first two methods are tolerance-based.
interval-certified uses rigorous numerical enclosures; exact-algebraic uses exact
arithmetic. Either supports verified only when the scoped certificate and its
preconditions are checked.
No amount of ordinary finite-precision checking buys that status: a numerical result
remains numerical at tolerance . Actual precision, rounding, and tolerance
are recorded alongside the method rather than implied by it.
Frontier proof evidence uses three further tokens—published-proof, proof-audited,
and proof-assistant-checked—for claims whose warrant is an argument rather than a
computation.
beat_record: true requires assurance: verified. A negative numerical gap is a
candidate or solver error, never a formal discovery—a rule that caught a critical defect
when a loose LP tolerance returned a packing violating its own separation constraint.
Even a verified feasible witness establishes only an upper bound; optimality needs a
matching verified lower bound.
Contact graphs, stationary branches, and rattlers
An exact reconstruction needs more information than a contact graph. A contact graph has one vertex per square and an edge for each touching pair, with optional wall vertices for boundary contacts. It says who touches whom, but not which equation makes them touch. For rotated squares, that equation also depends on whether the features are corner-edge, edge-edge, or wall contacts; which square owns the supporting axis; the separation order and sign; and the angle and wall chart. A typed contact retains those choices.
Fixing one consistent set of types gives a smooth support branch of the otherwise disjunctive feasible set. A complete branch contains one typed constraint for every square pair and wall, including inequalities that are not tight. Write the configuration vector as
q = (s, x_1, y_1, theta_1, ..., x_n, y_n, theta_n)and its clearance inequalities as . Row is active when . A feature tie occurs when several support descriptions apply at the same geometry, as at a corner-corner touch admitted by more than one owner-axis choice. The model must keep every applicable branch at a tie rather than choose whichever type a floating-point residual happens to prefer.
Fritz–John stationarity supplies the first-order equation on one branch. At a branch minimum there are nonnegative multipliers for the side objective and for the constraints, not all zero, such that
η ∇_q s - sum_j κ_j ∇_q g_j = 0, κ_j g_j(q) = 0.Here means the gradient with respect to the side, centres, and angles collected in . When , rescaling it to one gives the normal, or ordinary, Fritz–John branch and a Karush–Kuhn–Tucker (KKT) multiplier certificate. When , the objective drops out and a nontrivial dependence among active constraint gradients gives an abnormal Fritz–John branch. A proved constraint qualification—a suitable local regularity condition on those gradients—can rule abnormal branches out. Without one, omitting them makes an enumeration incomplete. Redundant or tied active rows can let one geometry admit both normal and abnormal certificates, so the two cases classify multiplier certificates rather than disjoint sets of geometries.
Activity and multiplier support are different. An active row may have : this is a zero multiplier, a tight contact that carries no first-order balance in that particular certificate. The rows with positive multipliers form the positive multiplier support. The contact graph induced by those rows may be smaller than the active contact graph and need not be connected.
A rattler is a square, or a cluster of squares, that can move locally within a cage while the remainder stays jammed. The jamming literature calls that rigid or force-carrying remainder the backbone. This project’s proposed typed stationary backbone is a broader proof record. It retains all configuration variables and every typed pair and wall constraint, then records the active subset, positive and zero multiplier states, support orders, angle charts, symmetry labels, and rattler attachments together with the continuous equations they index. Rattlers and inactive noncontact inequalities remain in the global feasibility problem even when they do not appear in the positive multiplier support.
These notions answer different questions. Stationarity is a necessary first-order condition for a branch minimum; rigidity means there is no nontrivial feasible local motion after declared symmetries are removed; and local isolation at fixed side says a proved fixed-side neighbourhood contains no other feasible pose. Passing any of them does not exclude a better packing elsewhere, so none by itself proves global optimality.
From a numeric solution to an exact one
Reconstruction starts from a numerical candidate and proposes an exact solution of a contact system. The final geometric checks decide whether that proposal is a packing.
You cannot “solve the constraints in the field”, for two independent reasons: you do not know the field yet—it is the output—and the packing constraints are inequalities, whose minimiser is not a solution of the constraint system.
The numerical candidate suggests which inequalities are tight. Those contacts supply equalities to solve; the numerical suggestion remains a hypothesis until verification.
The contact structure is the discrete hypothesis that crosses the float-to-exact boundary. Numerical coordinates may seed high-precision root finding or select a candidate root, but the final certificate must not trust them. Once the active constraints are hypothesized, the corresponding equalities are something algebra can solve and the complete packing can be independently rechecked.
- Numeric solve—propose, then quench.
- Read off the contact structure—which corner touches which edge, which corner touches which wall, which squares share an angle class. Everything downstream rests on this guess.
- Write and reduce the contact equations. The unreduced system still contains the centres. In several published rigid constructions, the chosen typed contact structure—often reported informally as a contact graph—lets one eliminate those centres and leave only and the distinct non-axis-aligned angles: two unknowns at , three at . That reduction must be derived from the particular contact equations; angle-class count alone does not perform it.
- Close an underdetermined system analytically. A local extremum of on the constraint manifold forces a rank drop, so the missing equations are Jacobian-determinant conditions—Lagrange/Fritz–John in determinant form. The condition is necessary rather than sufficient; roots that are not extrema are culled when the reconstruction is verified. The practical point is not elegance: it keeps the problem root-finding, which reaches thousands of digits, rather than minimization, which does not reach the precision the next step needs.
- Solve exactly—either by elimination (Gröbner basis in lex order, or resultants) or by high-precision Newton followed by an integer relation algorithm (PSLQ/LLL) that recognises the minimal polynomial.
- Certify. Both routes produce guesses, and both guesses must be discharged.
The two guesses, and why they matter more than the algebra.
- The contact structure. Step 2 decided that a residual separation at the solver
floor—
1e-11and below—is exactly zero. It might not be. Nothing in steps 3–5 rechecks this, so the reconstruction must be re-verified independently—numerical proximity does not guarantee algebraic correctness. - The minimal polynomial. Integer relation finds a relation, not a proof. A degree-8 relation holding to 500 digits is overwhelming evidence and zero proof. Irreducibility over must be checked, the intended real root must be isolated from the others, and the result substituted back exactly.
Certified numerics—interval-Newton, Krawczyk, Smale’s α-theory—can discharge an existence-and-uniqueness claim for a root of the declared contact equations. They do not identify the contact structure or recover a number field by themselves. A complete promotion still needs those discrete and algebraic claims bound to the certified root.
There is also a robust route that does not identify the source pose exactly: replace decimal centres and rotations by exact rational data, add an explicit side relaxation, and verify the resulting construction. This can prove a slightly weaker upper bound when the numerical pose has enough geometric slack. It does not certify the original decimal coordinates or preserve the reported value.
4. Certificates, Regularization, and Evidence
The capability boundary is stable even as individual tools change:
- numerical search and refinement propose candidate configurations;
- exact arithmetic or rigorous intervals can verify a scoped witness, certificate, or local statement once all of its preconditions are explicit;
- a fixed-angle LP settles only its declared cell and angles; and
- stationarity, rigidity, and fixed-side local isolation do not prove global optimality.
None of the listed capabilities proves global optimality by itself. T-060 proves it at by composing exact exclusions over a complete pattern cover, a symmetry reduction, a root induction with a capture graph, and exact local isolation; it is machine-checked here and reviewed, with its review record pending. A different route, a complete typed-stationary enumeration, would additionally need every support branch, including ties, abnormal Fritz–John cases, zero multipliers, inactive inequalities, and rattlers, followed by a global completeness argument. Describing that proof object does not establish it.
The synopsis capability ladder owns the
current implementation status and separates built paths, ordinary engineering, and
mathematically contingent steps.
packing-validate --list, run from packing/, is the live command inventory.
Section 8 records the claims actually established, with
their assurance and scope.
From a certificate to a registered result
A witness gives a concrete packing. A certificate supplies data from which a checker decides a declared claim: a witness can be a feasibility certificate, while a cover or exclusion tree can certify a lower-bound step. A replay runs the recorded check on retained inputs. Registration also needs the mathematical argument connecting what the checker decided to the whole claim.
The current epistemic policy separates four classifications:
verification (V), confirmation beyond the producing run (C), significance (S), and
novelty (N). Individual evidence still uses the assurance and method fields of
§3.
A whole result takes the evidence appropriate to its complete statement; a checked
component cannot stand in for an unchecked premise.
For example, an optimality equality needs both its construction and its global lower
bound. A sample can find a defect but cannot establish the untested remainder.
Rung 3 covers a checkable proof or complete replayable machine evidence. Rung 4 adds mechanized support, two adversarial AI reviews by distinct reviewers, and retained human oversight. Rung 5 requires the formalization and the specified human expert review. A source’s report that a Lean build passed is therefore different from a retained complete build and the review that earns the formal-verification rung. The exact rung predicates, including the difference between verification and confirmation, belong to Epistemics.
The degree of independence is recorded separately:
| Confirmation route | What the comparison can reveal | Shared risk |
|---|---|---|
| Replay the producer’s code | Missing, corrupted or irreproducible outputs | The producer’s implementation can make the same mistake again |
| Reimplement with named shared components | Errors in the rewritten portions | A shared parser, arithmetic kernel or other component |
| Independently implement after reading the producer’s code | Implementation errors the new code does not repeat | A copied interpretation or omitted case |
| Independently implement without reading the producer’s code | Errors in the producer’s reading of the specification | The mathematics or specification both implementations use |
Coverage and authoring overlap accompany that relation. Separate prompts or two programs from the same AI system family do not establish independent mathematical judgment. The independence record names what was read, what code was shared, who wrote it, and how much of the claim was checked. T-060’s complete confirmation reimplements the proof while sharing named components; T-154’s independent sample of ten finite facts leaves the full Lean build outstanding.
Regularization, exact sides, and credit
A regularization adjusts a known arrangement so its geometry reads more clearly: near-axis squares can become axis-aligned, intended contacts can close, and sub-blocks can align or become symmetric. The project retains the source witness and measures the new pose against it. A prettier drawing is not evidence for a stronger mathematical statement.
The regularization policy distinguishes three side relations. Let be the witness’s stated exact side or declared rational promotion, the view’s exact side, and the case’s verified upper bound.
| Relation | Exact comparison | Meaning |
|---|---|---|
same |
The view is at the witness’s side | |
bound |
, distinct from | The view is at a side the register already verifies |
solved |
Any other exact side | The solver produced a separately stated side |
The generator’s certificate and a same-side re-solve are separate possible outputs. The maintained routes verify every pair and wall, compare poses under the container’s eight symmetries, and check contact non-regression. The policy determines automatic admission and the cases needing human review; generator versions and review choices make the decision reproducible. A failed exact check cannot be overridden for display.
A view with must be considered as a register result before it becomes a drawing. Its relation to the source packing and its improvement over earlier certificates need separate evidence. Small movement can preserve an arrangement while improving its certificate; conversely a new pose may need different credit. The drawing keeps the source record’s evidence tier and never replaces the witness under the same name.
T-155 gives a concrete example: 59 exact rational certificates reduced recorded upper ceilings by between and . At 33 counts the same exact sides were already present in Daniel’s earlier certificates; the record had displayed rounded-up ceilings. The other 26 certificates reach slightly smaller sides. The result measures identity with the credited witnesses at 57 counts and leaves it undecided at 204 and 299. Neither a tiny improvement nor a regularizer’s output establishes a new packing by itself. T-156’s bound for 290 squares was already implied by T-155 at 291, by removing one square. These examples explain why exact side, certificate provenance, drawing identity, and novelty are recorded separately.
Intake is not adoption
The 14 October upper-bound ledger compares 306 claims at 163 counts in report order. It compares sides and verifies no certificate. Its “recorded” verdict applies the intake selection rule; a corresponding result, evidence package, and case-record adoption still have their own obligations. Likewise the retained reviews of wand125’s closed-form lower bound and the Fang excess theorem and certificates state the mathematics read and the computation reached. No tutorial claim of a stronger standing bound follows merely from those reviews being present.
5. Search Design and Its Limits
These strategies explain the retained early search campaign. Its negative measurements are scoped to those implementations and seeds. The methods survey connects the wider constructive and computational methods to the published records.
There are two layers: the catalogue of everything anyone has ever used, and the strategy this project actually adopted.
The catalogue
The campaign catalogues 28 search strategies in four families, with hypotheses citing the strategies they use:
- Constructive: grids, hand geometric insight, tilted families, diagonal strips, strip-plus-L augmentation, rational-slope tilts, composition and self-similarity, parametric families, asymptotic border constructions. The historical examples in the methods survey include Trump and Bidwell.
- Stochastic search: simulated annealing (the early campaign’s workhorse), billiard and inflation, basin hopping, nonlinear programming, SAT/CP, branch and bound over contact classes, evolutionary methods.
- Exact refinement: fixing a typed contact structure and solving the polynomial system, rigidity-guided enumeration, interval-verified local optima.
- Workflow: the human-computer loop against a public record table, which is how the tables actually advance.
A parallel catalogue of thirty proof strategies in six families covers the lower-bound side.
The strategy: why pointing should beat scaling
A validated map of terminal components is the intended deliverable, and records are corollaries.
The reasoning: annealing-class methods sample basins roughly in proportion to their volume at the sampling temperature, so they find the funnel whose entropy wins, not the funnel whose optimum wins. The canonical precedent is the 38-atom Lennard-Jones cluster, whose global minimum sits at the bottom of a narrow funnel beside a broad one that captures almost every unbiased run.
If that transfers, scaling the same proposer merely multiplies samples against a small fixed probability, and the response is to point search rather than enlarge it.
That reasoning is a precedent, not a measurement. It enters as a reason to expect a direction to be productive, never as a fact about this landscape. Contact counts do not establish rigidity; rigidity does not establish rare attraction; another author’s basin counts are a property of their proposer, not of the problem. The premise is registered as a hypothesis with a kill criterion—if record basins turn out to be hit at rates comparable to the modal basin, the cartography program stands down and the campaign reverts to throughput.
Steering: keep the loss, change what you keep
Reshaping the objective creates two problems. First, a naive contact reward favours grid-like arrangements, the opposite of the intended direction. Note the shape of the trap, because it recurs: the grid is high-contact and common; the record is high-contact and rare. Any single scalar they share cannot separate them.
A reshaped loss can change the minimizers unless equivalence is proved. Lexicographic tie-breaking, potential shaping, or an auxiliary term that vanishes on exactly the same minimizers may preserve the target, but that preservation becomes a separate proof obligation rather than an intuition.
The alternative keeps the objective and changes what is retained: a quality-diversity archive keyed by structural descriptors. In exploration mode, a taboo on canonical keys can avoid spending proposal budget on a named endpoint. In measurement mode, repeated hits are essential data for proposer-conditioned frequency and uncertainty, so they must be counted rather than suppressed. The intelligence and the risk concentrate in descriptor design: descriptors must come from verified canonical data rather than raw floats, must be axes of mechanism, and must be combined so as to separate the grid funnel from oblique structure.
Relaxation ladders: turn rare-event search into path-following
Embed the hard instance in a one-parameter family whose far end is easy, then track solutions along the parameter instead of searching for them cold.
| Ladder | Parameter | Easy end | What to watch |
|---|---|---|---|
| container inflation | slack in side | large : hypothesized broader accessibility | basin splits and merges; the first observed or certified at which a named target is reachable |
| superdisk | exponent in | : circles, orientation-free; : the square limit | where orientation symmetry breaks |
| boundary layer | frozen grid bulk | the pure grid | whether a sheared band re-synchronizes |
Container inflation is the primary one, and it can pay three ways from one computation: a method that may walk into regions direct sampling never hits, the barrier scale a map wants anyway, and a scalar hardness measurement. That scalar becomes well posed only after naming the proposer, target component or event, success threshold, and whether the quantity is an observed branch-entry scale or a certified clearance barrier. Boundary-layer reduction is strictly a reduction, not a relaxation: the slice may exclude the true optimum, and that risk is stated rather than hidden.
Calibration must match mechanism, not just difficulty
The proved cases used as positive controls, and , are both mechanisms (the other proved small cases are plain grids). They validate machinery, not strategy—an engine can take them to machine precision and remain structurally blind to the irrational oblique tilt that demands. T-060 has since supplied a proved oblique case; the earlier experiments did not acquire that coverage merely because its status changed.
So record-finding needs its own targets, chosen by mechanism: the nearest case whose record uses genuinely oblique structure, the target at small inflation (which gives a graded progress metric along a tracked branch, without assuming continuity across bifurcations), and basin-entry tests that separate “search cannot find the region” from “the refiner cannot hold it”—two failures with identical symptoms and different fixes.
The result that most sharpened this: the annealer, pointed at , reported — the trivial grid—on every one of five binary64 screening seeds (exp-011), against Bidwell’s 1998 record of . Because that miss is at a second, independent cell whose record needs oblique structure, the failure is not specific to ; whether it covers every oblique target is an inference the registry states as such, not a theorem.
Near-misses are the data
A campaign produces thousands of non-record endpoints. These supply the map, the training set for descriptors, the sample for structure-versus-rarity laws, and the denominator for any coverage claim.
6. Lower Bounds by Weighted Covers
The state of n = 11, in one table
| value | status | |
|---|---|---|
| best-known packing (upper bound) | Trump 1979, a construction | |
| verified lower bound | , Trump’s side exactly | Ahmed 2026, Astra-assisted and building on this project and Overbeck; machine-checked here and reviewed, review record pending (T-060, V3/C3) |
| earlier verified lower bound | , strict | Overbeck 2026, developed from T-026’s certificate and confirmed here by two complete coverage methods (T-037); superseded by T-060 |
| strongest first-party lower bound | T-033, T-026’s atoms on a finer net; the point-only T-018 proof is explained below | |
| gap between the verified bounds | settled: is Trump’s side |
T-022 refines
the point-certificate bound to .
T-024 rechecks
the point atoms on a finer direction net and proves .
T-025
introduces threshold atoms and directly proves .
T-026
proves
,
those same atoms re-certified on a finer direction net and dilated; T-033 repeats it on
a net twice as fine for . Overbeck’s starts
from T-026’s certificate and restricts coverage to what a real parent square needs; it
lies above T-033 and about below Trump’s packing.
T-026 checks a finite certificate on the finer net, proves that common scaling preserves
its coverage and budget whenever the strict containment inequality holds, and uses
rational density to establish the displayed ≥ bound.
This is a proof of the lower bound, not a weaker kind of assertion.
The phrase dilation-limit proof names how the theorem is derived; it is not an
assurance grade.
Under this repository’s epistemic scale, T-026 is V3/C3:
machine-checked, with its review record pending.
V3 means the result has exact or interval-certified evidence, a frozen certificate, a
replay command, and a passing replay; C3 means that certificate was replayed here.
The finite certificate’s coverage condition was confirmed by two distinct methods, an
exact event-cell sweep and an interval branch-and-bound, which the register records as
an attribute beside the rung rather than as a rung of its own; they share the
certificate data and theorem, so two methods do not mean two independent proofs.
A
mapped, non-superseded source-distinct review
of the complete T-026 claim, including the threshold count, finite decision, dilation,
and endpoint inference, is retained; rung 4 on either axis also needs a second
adversarial review by a distinct reviewer and a retained human oversight record, and
rung 5 formal verification reviewed by human experts, so until those records exist the
result stays at V3/C3. These labels describe the retained evidence and confirmation;
the mathematical claim is the proved lower bound above.
The detailed lesson below starts with the simpler point-only T-018 certificate; the standalone explainer uses it as a visual worked example, then gives the threshold-counting and dilation proof of T-025 and T-026. The numerical result is not a premise of T-026. T-018’s short standard-library checker exposes the shared geometry and counting mechanism end to end. That point-certificate checker does not verify the threshold certificates. The explainer is Part I of a series on , read in order: Part II reviews Overbeck’s certified bound (T-037), and Part III reviews the proof that Trump’s packing is optimal (T-060). The linked T-025 and T-026 claim documents each embed the standard-library threshold verifier and the exact certificate bytes it checks; T-026 also embeds and re-derives its dilation record.
Two different quantities get called a gap in this subject, and this document keeps them
apart. The bound gap is the distance between the best upper and lower bounds, the
part of still unknown; for it is now zero.
A search gap is best_side − standing best, the signed distance from one packing
this project found to the best one anybody has published, and it is what
§2 onward measures.
The first is a property of the problem; the second is a property of a run.
The previous lower bound also led to a proof repair. Stromquist stated in his 1984 Memo III, p. 10, without supplying the unrestricted proof there. His 2003 Theorem 2 was the published presentation, and this repository found that its printed proof is false as printed: an exact open box of side fits the claimed container and strictly avoids all twelve printed Figure 14 points. A separately preregistered, source-distinct repair—moving one point from to —restores the whole argument and certifies the same inequality exactly (exp-016, exp-017). The repaired argument proves the inequality; the printed derivation does not. The synopsis records the repair as T-4 and the falsification as the round that terminally refuted the hypothesis it was registered against. That value is no longer the best lower bound for ; displacing it was the point of the certificate below.
The episode is why this repository treats published proofs as source claims and tests them with exact counterexample searches.
How a weighted atomic lower-bound proof works
The certificate below turns a lower-bound claim about continuously many packings into a finite exact check. The covering LP finds candidate weights; the geometric transfer and exact coverage check establish the theorem.
An explicit construction supplies an upper bound that can be handed over and checked. A lower bound has to exclude every packing at once. The worked proof below shows how a finite certificate can do that. The proof of , T-018, uses a finite exact certificate and is short enough to follow from first principles.
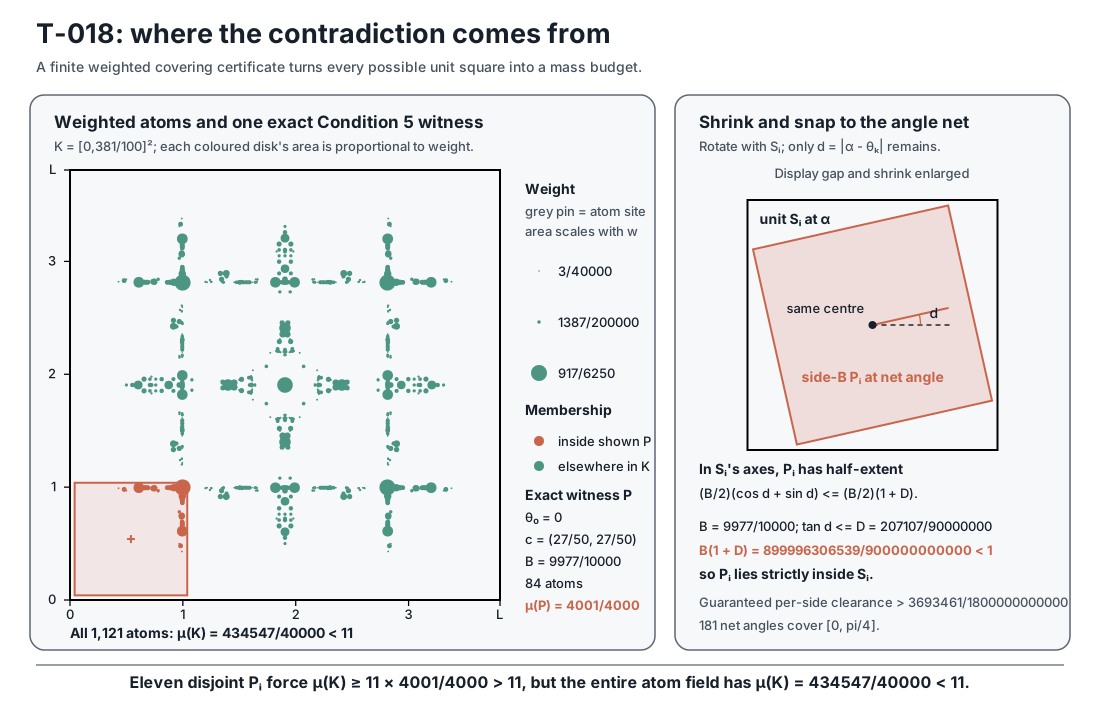
Fix a candidate container —here . An atom is an exact point in together with a nonnegative rational weight . An atom has no width and blocks nothing: it is bookkeeping mass, not a packed square. For a region , the atomic measure assigns the mass
μ(Q) = Σ { w(z) : the atom z lies in Q }and a closed square covers mass when the weights of the atoms on or inside it sum to . Atomic means every unit of mass sits at one of finitely many points rather than being spread continuously across the container: the retained certificate puts its mass on 1,121 distinct rational sites, all weights positive.
This is a fractional version of an unavoidable point set—the device Stromquist’s own argument uses, where every admissible square is required to contain a marked point. Here several atoms may instead contribute fractional weights that add to at least one, and that flexibility is what lets a covering linear program search for the weights. Stromquist’s earlier proofs also use geometric helper arguments: his six-square proof forces one square to contain four of eight dots, and the repaired eleven-square argument forces one square to contain three of twelve. Those forced allocations strengthen the final counting contradiction. The certificate below uses an unconditional weighted cover; the memo review examines how the helper steps could be made systematic. The weighted-certificate theorem is Burns’s and Massaccesi’s; the instance and the generator that found it are this project’s. The finished proof uses none of the search—only the frozen rational atoms, the nonnegativity premise, and five exact conditions.
| Condition | Exact fact in the certificate | Its job in the proof |
|---|---|---|
| Condition 1 | The weighted atoms are invariant under the container’s symmetries (the four rotations and four reflections of a square) | Reflect an orientation onto the net’s arc without changing any covered mass |
| Condition 2 | μ(K) = 434547/40000 = 10.863675, which is below 11 |
Supply less total mass than eleven packed squares would have to consume |
| Condition 3 | A net of 181 exact directions reaches | Put every reduced square orientation between two checked directions |
| Condition 4 | , for and | Fit a closed side-B square at a nearby net direction strictly inside any unit square |
| Condition 5 | Every admissible side-B square, at every net direction, covers mass at least |
Give each inner square strictly more than one unit of mass |
The counting contradiction. Suppose eleven unit squares did fit in with disjoint
interiors. Inside each one put the side-B square that Conditions 3 and 4 supply.
Those inner squares are closed but lie strictly inside their parents’ interiors, so they
are pairwise disjoint and no atom is counted twice.
Condition 5 gives each of them mass at least . Nonnegativity and
Condition 2 then force a chain that cannot hold:
μ(K) ≥ μ(P₁) + ··· + μ(P₁₁) ≥ 11 × 4001/4000 = 44011/4000 = 11.00275,
yet μ(K) = 434547/40000 = 10.863675.
So eleven unit squares do not fit at side . Any packing in a smaller container would also fit inside , and therefore .
How 181 directions cover every orientation. A square is unchanged by a quarter turn,
and a diagonal reflection reduces its angle into while Condition 1
leaves every covered mass alone.
The net directions are , carried as rational half-angle
tangents so that their sines and cosines stay rational.
For an arbitrary reduced angle, take the nearer endpoint of the net interval containing
it and call the angular error ; the net’s spacing bounds exactly.
Measured along the unit square’s own axes, a side-B square at that net direction
reaches from the shared centre by at most
(B/2)(cos d + sin d) ≤ (B/2)(1 + D) < 1/2so it fits strictly inside the unit square. That shrink is the bridge from a continuum of orientations to a finite net, and it is what stops the argument from assuming an unchecked orientation behaves like a sampled one.
How event cells cover every centre. Even at one fixed direction the inner square has
continuously many admissible centres.
Rotate the frame to align with that square.
For a single atom, the centres whose closed side-B square covers it form a closed
axis-aligned rectangle.
The edges of all 1,121 rectangles cut the region of admissible centres into finitely
many open event cells, and inside one event cell exactly the same atoms are covered,
so the covered mass is constant.
On a cell boundary a closed square can only gain atoms, and because every weight is
nonnegative its mass cannot fall.
Scoring every reachable open cell therefore decides the true minimum over every centre
rather than over a grid of sampled ones—which is what makes Condition 5 a statement
about the continuum instead of a survey of it.
Why nonnegativity is essential. It does two jobs, and neither is decorative. A subset cannot carry more mass than the whole container, which is what makes the counting chain valid; and adding boundary atoms cannot lower an event cell’s score, which is what makes the finite sweep a minimum rather than an estimate. Allow negative weights and both fail: an atom gained on a boundary could reduce a score, and negative mass outside the eleven inner squares could make the container’s total misleadingly small.
The proof and the computation meet at Condition 5. Symmetry, total mass, the net’s
endpoint and the shrink are short rational calculations a reader can redo by hand.
Condition 5 is the large finite lemma, and it is what the exact event-cell sweep and
the method-distinct interval branch and bound in
sqpack.fractional each decide from the
certificate’s frozen bytes, agreeing on to the digit.
How the finite covering LP searches for atoms
A site and a square pose play different roles.
A site is a point where the search may put an atom.
A pose is one square at one centre and angle.
In the proof regime above, the admissible side-B net squares form a family containing
all the strict inner cores used by the proof.
Choose a finite site set and a finite pose set . The covering
linear program is
minimise    Σ { w(x) : x ∈ 𝒳 }
subject to  Σ { w(x) : x ∈ 𝒳 and x ∈ Q } ≥ 1    for every Q ∈ 𝒫
            w(x) ≥ 0                              for every x ∈ 𝒳.
The matrix has one row per pose and one column per site. Its objective asks for the least total dot weight that covers every held pose by at least one. This finite program is only the search problem. Omitting poses makes it easier, while restricting the atom locations to held sites makes it harder, so its value has no general ordering against the unrestricted continuum problem.
The generator repairs the two omissions in opposite directions.
Row generation searches all event cells for a pose whose current covered mass is
below one and adds its constraint.
Adding a row can raise the covering objective.
Column generation adds a promising atom site, giving the primal more freedom, so the
objective can fall or stay fixed.
The finished certificate still needs the shrink, boundary, and all-angle arguments
already given above.
In particular, its closed side-B cores lie strictly inside the physical unit squares;
otherwise two touching physical squares could share a boundary atom and invalidate the
counting sum.
The dual program explains which missing site to try. It puts a nonnegative weight on each held pose and maximises their total weight, subject to
depth_y(x) = Σ { y(Q) : Q ∈ 𝒫 and x ∈ Q } ≤ 1 for every held site x ∈ 𝒳.The poses with form the dual’s support. The dual can be read as a fractional packing: poses may overlap, and fractions of many poses may pass through one point, provided their total depth at each held site is at most one. This is not a physical packing of disjoint unit squares. Duality says its total weight lower-bounds the minimum covering mass for the same finite rows and columns.
Now evaluate depth_y(x) at a site not yet in . If it exceeds one, the
current dual violates the constraint that this missing column would impose.
Its reduced cost is 1 − depth_y(x), so negative reduced cost identifies a useful
candidate atom location.
This search for a missing site is called pricing. The symmetric implementation adds
the point’s entire orbit , obtained by the container’s rotations and
reflections, and checks that the whole orbit is absent.
One orbit variable assigns the same per-point weight to its images: its objective cost
is , and its coefficient in pose row is the number of orbit points
inside . The symmetrised dual has equal depth at all orbit images, so the orbit’s
reduced cost is |O|(1 − depth_y(x)) and has the same sign as the pointwise expression.
Adding the orbit creates one primal orbit variable and one aggregated dual constraint.
It need not force a strict objective change: a different old dual optimum may survive.
Determining the new optimum requires resolving the enlarged LP.
A support cap can hide that signal. For a toy point, suppose the first 32 support rows contribute depth and the remaining positive rows contribute . The capped family reports , while the full family reports at the same point. Those numbers are illustrative, not a measured result.
H-135 turns that
example into a controlled test.
It uses one finite LP solve and one largest-first sequence of positive dual entries
retained under the protocol’s selection threshold, rationalised once; paired32 takes
the first 32 entries and full takes them all.
Success requires one new point whose complete orbit is absent and whose exact
rational depths at the same point satisfy
depth_paired32(x) ≤ 1 < depth_full(x).That outcome would show that the 32-row cap hides a violation in this rationalised
proposal. It would not establish a strict objective improvement, identify the cause of
any historical stall, certify the rounded weights as a feasible or optimal dual, or
prove a packing bound.
Here “full” means the positive support of this one finite solution, not all square poses
in the continuum. The dated
exp-134 protocol
records an administrative blocked, unrun disposition: no target was invoked before the
owner reprioritized the allocation.
It supplies no scientific verdict on the mechanism.
That experiment transports the retained state to unit-square poses for a pricing
mechanism test; it is not the side-B primal-cover theorem used by T-018.
The threshold explains what either side can eventually prove.
An exact atomic cover of all admissible strict cores with total mass below 11, together
with the transfer above, excludes eleven physical squares.
Conversely, an exact fractional family of total weight at least 11 whose depth is at
most one at every possible atom location would rule out that unconditional cover
route for the fixed core family.
It would not exhibit a physical packing or rule out other proofs.
The
retained side-B depth-one baseline
at has mass , below 11, so it is
inconclusive: it is neither the desired cover below 11 nor an obstruction at that
threshold. A later
88-core family
at the same side and core size has total mass exactly 11 and point depth at most one.
It therefore obstructs every unconditional point-atom cover below mass 11 on that fixed
core domain. Scaling the cores and placements by gives a mass-eleven family
of full unit squares in side ; selecting any individually defined core
inside each parent preserves the point-depth inequality.
This extends the point-only obstruction to those selections at that side and above.
It does not apply below that side or to threshold charges, conditional domains, or
restrictions that depend on the other packed squares.
Threshold atoms and dilation
A point atom charges a core for containing one site. A threshold atom charges whenever the core contains at least sites from a finite set . Because the strict cores are disjoint, at most of them can trigger that atom, so its total budget is . Adding point and threshold charges gives the counting bound: if each core must carry charge at least one but the combined budget is below eleven, eleven cores cannot fit. T-025 uses 584 point atoms and 320 threshold atoms, each a 2-of-3 atom, with total budget . Its verifiable claim contains the precise coverage and strict-containment obligations.
A dilation-limit proof rechecks a certificate on a finer direction net, then scales its sites, cores and container together. Scaling preserves the coverage relations and budget; the strict containment inequality determines how far it can go. Rational scalings approach a limiting side from below. Every smaller real container embeds in one of those excluded rationally scaled containers, so a density argument proves the lower bound at the limit. The limit need not itself satisfy the strict shrink test. T-026 retains the finite checks and the endpoint argument separately.
Why condition on corner squares?
An unconditional cover treats each square alone. Structural information can instead split the possible packings into cases and give each case its own atomic measure. Only proved restrictions on corner ownership, wall contacts, angles, or compatibility may remove poses. Every hypothetical packing must belong to a case, and its certificate must cover every legal core throughout that case’s continuous parameter range.
A strict core is a slightly smaller square—side here—placed strictly inside a physical unit square. The strict inset makes the closed cores of non-overlapping physical squares disjoint, including at their boundaries. A corner owner is one of four distinct physical unit squares whose selected core contains a chosen mark, a specified point near a container corner. The owner may still move and rotate within its case. A guaranteed footprint is a fixed closed polygon that lies inside the owner’s selected core for every pose allowed by the case. It records area that is certainly occupied even though the owner’s exact pose is unknown.
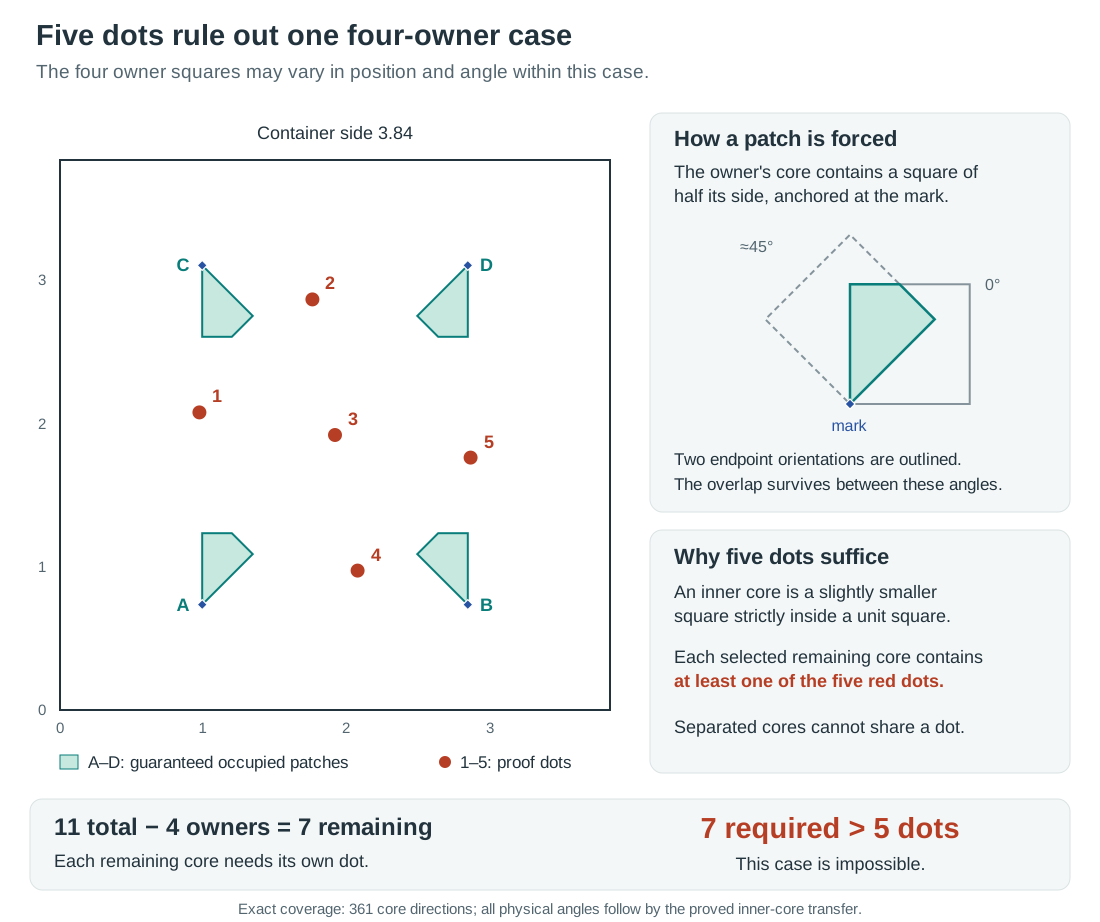
The proved five-dot exclusion for one selected four-owner branch at L = 96/25. The
corner shapes are the regions guaranteed to lie in the four owner cores; the five dots
pierce every selected remaining net core.
The drawing explains the logic; the linked records supply the exact check and the
geometric proof that extends it to every physical angle.
Here is the counting argument for that branch.
- Four distinct corner owners are already identified, so an eleven-square packing would have other squares.
- Every strict core of a remaining square must avoid the four guaranteed footprints.
- Use the five fixed dots shown in the figure. Their exact coordinates and the full worked example are in the sprint report.
- The exact full-net replay checks all 361 chosen core orientations and finds that every admissible remaining net core contains at least one of those dots. The reviewed shrink-and-snap argument transfers the finite orientation check to physical squares at every angle (five-dot transfer review).
- No dot can serve two cores: each strict core lies inside a different physical square’s interior, and those interiors do not overlap. Five dots can therefore meet at most five residual cores, fewer than the seven the branch requires.
This proves that an eleven-square packing at side cannot belong to this selected branch. The result is registered as T-023. It does not prove a new lower bound for . The corner-owner theorem permits other owner classes and sectors, so a global result would need to prove that every hypothetical packing admits at least one valid selection excluded by a conditional certificate. Excluding every raw label or every permitted combination is sufficient but stronger than this selection requirement. The numerical source receipt records how the five dots were found; the exact replay and transfer review establish the covering claim.
To follow past this tutorial’s scope, read the synopsis’s
n = 11, End to End.
That section is a dated account of the case before T-060 settled it.
It covers the ceilings these certificate languages reach, the external certificate that
held the verified lower bound before T-060, and why the strict-core counting
certificates studied there cannot prove equal to Trump’s side.
7. Global Optimality by Exclusion and Capture
§6 proved a lower bound by counting,
and §4 said that
T-060 settled by composing exact local
isolation, a complete pattern cover with exclusions, a symmetry reduction and a capture
graph.
This section explains those pieces in general, as they apply to any whose best
known packing is to be proved optimal.
, where the proof is complete, and this project’s own route at ,
suspended on 13 October 2026 pending Overbeck’s proof, which the owner judged likely to
subsume it (item 7 of §8), supply the illustrations;
the n = 17 explainer gives that
route’s numbers, records and status, and nothing below is a result about the case.
Three parts
The strict-core counting certificates developed above prove below the known
side.
Their strict shrink and budget mechanism cannot reach that side, for the reason the
synopsis’s n = 11 account gives.
The exclusion-and-capture route to proving optimality has three parts.
- The local half. Nothing near the known packing is smaller: every packing whose coordinates lie within an explicit radius of it, in a sense the theorem makes precise, has side at least the known side, with equality only on the known packing or its family.
- The global half. Every packing of side at most the known side falls into one of finitely many occupancy states, and every state but the known one is proved impossible.
- Capture. A packing in the known state is close enough to the known packing for the local half to apply.
The first is a theorem about a neighbourhood whose radius is a number such as . The second is a finite case analysis over regions of width about . The third bridges those two scales, and it is the part with the most engineering in it.
The cap above the optimum
The global half does not work at the known side, which is an algebraic number of some degree, but at a cap: a rational container side slightly above it. Two facts make a cap the right object. Any packing of side sits centred inside , so a state proved impossible at the cap is impossible at every smaller side, the known side included. And the known packing must itself be a legal case, with room: its state must survive every exclusion, and no translation the cap allows may carry it across the seam between two states. The proof ran everything at a cap about above Trump’s side; the work runs its exclusions at , about above the known side.
A cap that serves exclusion can defeat capture. Near a known packing the side rises at some least rate per unit of displacement in the softest direction. At a cap , a packing can therefore move about in that direction and still have side at most ; those are packings of side above the optimum, and no sound argument excludes them. If that distance exceeds the local half’s radius , the claim “every packing in the known state with side at most the cap lies within of the known packing” is false. Capture therefore needs a cap within about of the known side, which for means a second cap , taken from a rational enclosure of the known side, with the cover’s cells kept in the frame of the first and only the wall bounds moved (specification, section 4.1). At one cap served both purposes; the completed capture proof establishes that its surviving states reach the declared local region.
The centre box and capacity-one covers
Why a finite list of states exhausts every packing takes four steps, each of which is an exact statement a checker proves.
Centres lie in a box. A unit square inside has its centre at least from every wall, since its reach along a wall normal is . So every centre lies in the centre box .
Finitely many closed cells cover the box. A cover is a list of closed polygons, called cover cells here, whose union is the centre box; the proof is an exact sweep, or an inclusion–exclusion sum showing the union’s area equals the box’s, since a closed cover with no missing area has no missing point. The cover had 16 Voronoi cells; the cover has 24: four corner squares, twelve wall rectangles and eight interior Voronoi cells.
Each cell holds at most one centre. This is capacity one, and the basic proof is a distance argument. Every unit square contains the open disc of radius about its centre, so two squares with disjoint interiors have centres at least apart, in every orientation, and a closed cell of diameter strictly below holds at most one centre. The strictness matters: two squares both oriented along a chord of length exactly one touch edge to edge with the chord’s endpoints as their centres, so a closed cell of diameter one can hold two. The cells all had diameter below one. A cell against a wall can be wider than that and still have capacity one, because the wall stops one square from retreating: the depth-width wall lemma bounds the separating gap of two contained squares with centres in a cell of depth from the wall and width along it by for a separating normal in the quarter circle, and if no such pair exists. The lemma is sharp, so the condition is also necessary, and a checker proves the sign on closed rational angle intervals (lemma review). The wall and corner cells rest on it.
So every packing names a state. Assign each centre a closed cell containing it. Capacity one makes any such assignment injective, so the centres name distinct cells: an -subset of the cover, which is an occupancy state. A cover of cells has states, and that binomial is the whole census before any exclusion. Cells may overlap, in which case a packing with a centre in an overlap names more than one state; that is harmless for exclusion, since a certificate about closed cells holds under any assignment, and it matters for capture, which must know that the known packing, with every motion that keeps its side, lies in exactly one state with a margin.
The cell count drives the census. Sixteen cells for eleven squares give states; the 20-cell cover the proof first tried would have given , and a grid for with some cells of capacity two counted like a 30-cell cover, over a hundred million states. A minimal cover of capacity-one cells is the single largest factor in whether the global half is affordable (bulk-exclusion design).
Symmetry and orbits
The container has eight symmetries, the dihedral group of §6’s Condition 1. When a cover is invariant under a group of those symmetries, each symmetry permutes its cells, and a symmetry carries a packing in one state to a packing in the image state; so a state is impossible exactly when all its images are. An orbit is a state together with its images, and proving one representative proves the orbit.
How many orbits there are is not the state count divided by the group’s order, because a symmetric state has fewer distinct images than the group has elements. Burnside’s lemma gives the count as the average, over the group, of the number of states each symmetry fixes. The cover was invariant only under the half-turn, and no 11-subset of its 16 cells is fixed by a half-turn with no fixed cell, since a fixed subset would be a union of pairs and so of even size; the lemma gives orbits, and entered that proof at the end, through a bridge, rather than in the census. The cover is invariant under all of , and some of its states are fixed by reflections, so its orbit count exceeds one eighth of its state count; a brute-force reduction of every state to its least image is the check on the lemma.
Sub-pattern exclusion by containment
A sub-pattern is a set of cells. It is forbidden when unit squares, each centred in its own cell of the set, at any orientations, inside the cap container, cannot have pairwise disjoint interiors. The other squares are unconstrained, which is what makes a forbidden sub-pattern transfer: every state containing it, or any symmetric image of it, is impossible, whatever the other cells do. One certificate of arity five to seven can exclude hundreds of states at and tens of thousands at . At , 59 such certificates excluded 1,904 of the 2,180 cases; the remaining 276 needed a geometric exclusion each, at about 636 CPU-seconds apiece.
The counting is done by an exact consumer: it enumerates every state, removes those containing an image of a certified pattern, and takes the union as a set, never by subtracting counts, since two patterns’ exclusions overlap. The known packing’s state must survive every certificate; one that excludes it is a soundness failure of the prover, not a result.
Selection versus certification
Which sub-patterns to try to certify is a search problem, and a heuristic may propose them. A selector searches hard for a placement of each candidate pattern, by penalty descent from many starts, and flags the pattern when every attempt leaves positive penetration. A flag certifies nothing. It is a failed search, and the number it reports is the best violation found, not a margin: at the reviewers’ own searches found placements violating by less than the selector’s figures. A false flag is a pattern the search failed to place although a placement exists, and its cost is what makes a prover necessary rather than a formality: at , two flags that a later search placed would together have removed half the census, and an exclusion built on them would have been a wrong proof with a plausible count. The selector proposes, the prover certifies, and only what the prover certifies enters the consumer.
What makes a certificate admissible
Two kinds of prover have been used here, and they share no code. An ownership induction keeps, for each owner (a cell with one square in it), a closed partition of the square’s orientation into angle rows, each with a residual, the closed polygons holding every centre the owner can have at those angles, and an owned hull of points proved to lie strictly inside the square in every surviving pose. One step updates one owner against the others: it removes centres that would put another owner’s owned point inside the square, removes centres at which the square would overlap a partner in every pose the partner can still take (a collision region), and proves by an exact sweep that what is left is covered by the proposed residuals; points inside the square at every surviving pose are promoted into the hull. The node closes when some owner has no pose left or two owned hulls meet, and a stall is a sound statement that these rows exclude nothing. An interval branch and bound instead branches on the angles and decides the centres on each angle box by a linear program; the solver only proposes multipliers, and a node closes only when their combination, evaluated with every operation rounded outward, stays strictly positive on the whole box, a Farkas closure. A run that reaches its resolution floor or depth cap is unresolved, never certified. In the cited work, each prover closed a pattern the other could not.
A closure is not yet a result. A certificate is a saved object, named by the hash of its canonical bytes, that a reader can check without the program that produced it. Admitting one asks for four things.
- A fresh-process re-check of the saved objects, with the producer never imported.
- Independent verification in separately written code that imports nothing from the prover, together with a mutation suite: deliberately unsound variants of the objects, or of the prover, that the checker must refuse. At the branch and bound’s own witness-path controls caught four of sixteen unsound mutants and the certificate check every one that produced an invalid record, which is why the certificate check, not the controls, is the admission gate.
- Falsifier controls: patterns that must not close, run through the same code at the same settings, such as the known packing’s own sub-patterns and the certified pattern with one cell removed, which the selector places.
- A ledger that records each certificate as pending or admitted, with the review that admitted it; the census counts only admitted entries, reports pending ones as a separate projection, and refuses to report any count at all if an entry fails a check.
A local minimum modulo sliders
The local half for an isolated packing, such as Trump’s at , is local isolation: within an explicit rectangle around the known pose, no other feasible pose exists, and the known pose spans the container, so no smaller side fits there. A known packing need not be isolated. At one square is free and three slide without changing the side, and the local half must then be a local minimum modulo sliders: with the free square dropped and the slides left free in a declared box, every packing whose remaining coordinates lie within a radius of the family’s lies on the family, which spans the container at every slide.
The proof is first-order with a worst-case remainder. A stress is a set of nonnegative weights on the tight contact and wall rows whose weighted sum of gradients is exactly the side’s gradient; it is first-order stationarity and nothing more. If the rows with positive weight span every direction except the sliders, then for each signed coordinate direction there is a nonnegative combination of rows, a dual, that pushes a displaced packing back by its displacement. Each row’s curvature over the box is bounded by a rational constant. The ratio test compares them: if a packing in the box were off the family, some coordinate would be the most displaced relative to its radius; the dual for that direction says the first-order terms push it back by at least its displacement, while the curvature constants say the remainders can push it out by at most a multiple of the displacement squared; and when that multiple times the radius is below the displacement the only solution is zero. The same arithmetic, replayed on the duals, reproduces that proof’s worst ratio exactly.
The theorem’s two premises matter more than its arithmetic. The radius the ratio test certifies is the capture target: the global half must deliver packings within , in the theorem’s frame and angle chart, or the local half does not apply. And the slider box is a premise the local theorem cannot supply for itself: with the free square dropped, nothing in the theorem bounds how far the sliders go, and a claim that quantifies over every physically feasible slide can be false, because exchanging two squares can give a valid packing of the same side far outside the box. The usable theorem therefore carries the occupancy state as a premise, and a separate lemma shows that the free square’s cell bounds the slides (composition review).
Capture
Capture must show that every packing in the known state, at the capture cap, lies within the local radius of the known packing, in the frame the local theorem uses. The engine is the ownership induction again, now with every owner contracting, and its power lies in the angle rows: inside a narrow row the angle contributes half the row’s width rather than its whole range, positions contract to that scale, rows die, and the width of an owner’s surviving rows shrinks by a contraction factor per round of updates. The number of rounds grows like , so the radius is a weak cost driver and and the number of leaves dominate; a factor near one is a stall whatever the radius. When an owner’s residual becomes bimodal the tree branches on a closed predicate, and the far leaves end in contradictions. At the factor averaged about , the tree had ten nodes and four leaves, and the checker replay cost about two CPU-hours; the discovery cost of the splits and orders was never published, and it is the larger unknown (capture costing). Soundness has one more control: after every certified update the known packing’s exact pose must still lie in some live row of every owner, and losing it is a failure of the prover, not a discovery.
Why exact arithmetic dominates the cost
The ownership induction uses exact rational arithmetic; the interval route uses rigorous outward rounding. Both must decide their inequalities on entire declared regions. A tolerance that silently accepts violations would leave a hole in the proof. Every clip and hull multiplies denominators, so the cost of a step grows with the depth of the induction; the root needed an integer homogeneous backend for tens of millions of inequalities. In the ownership induction the collision regions dominate, since each tests every vertex of a region against every facet of a Minkowski difference for every live row of a partner; in the branch and bound the cost is the node count, which multiplies as the margin of the pattern shrinks. Three things keep it tractable: a strict core and a chart that make every test a polynomial inequality, as in §3; certificates that are independent of each other, so they run in parallel without coordination; and the division of labour in which a floating-point producer proposes and an exact checker decides, so the search is cheap and only the proof is exact. A compiled evaluator for the per-node bounds is the obvious further speed-up, and at it is unbuilt.
8. Results and Open Questions
The established claims below state their limits; the open questions are ranked by how
much of the program rests on them.
Assurance and method follow §3.
Provenance is a separate fact from assurance, so each row states it.
A published result checked here is a confirmation; the evidence register separates
those (previously-published) from elementary facts nobody claims (common-knowledge).
A result first established here may be apparently novel: new to the best of this
project’s knowledge from its retained source search.
That is an assessment of the search done, not an assertion of priority.
External review is a separate attribute and must be supported by its own record.
The synopsis’s
Assurance, Methods, and Claims owns the
definition and the one-place list of apparently novel results.
For in particular, n = 11, End to End keeps,
as a dated account from before T-060 settled the case, the bracket as it then stood,
what each result does and does not prove, and the hypotheses and ideas then open, under
the same distinctions.
Established
| Result | Assurance or basis | What it does not say |
|---|---|---|
| Fixing the angles and every pair’s separating axis makes minimising a linear program | proved | Nothing about which cell is best; that choice is the combinatorial hard part |
| Trump’s 1979 packing is valid, over of degree 8, with 14 pairs at exactly zero separation | verified (exact-algebraic); a published construction, confirmed here |
Nothing about optimality; it is an upper bound |
s(11) ≥ 2 + 4/√5 |
verified (exact-algebraic) |
Not attributed to Stromquist, not externally peer-reviewed, and it does not close the gap to Trump |
| T-025 proves ; T-026 proves | Both are V3/C3: machine-checked exact and interval-certified evidence with passing replay, distinct exact event-cell and interval coverage decisions, and mapped non-superseded reviews; the human oversight record rung 4 needs is pending |
Neither result determines or closes the gap to the best-known packing; V5 or external review would be a separate assurance step |
| T-060: Trump’s packing is optimal, so , his side exactly | V3/C3: machine-checked here and reviewed, review record pending. Ahmed’s proof, Astra-assisted and building on this project and Overbeck; a published result confirmed here |
T-112 separately records the uniqueness corollary at V3/C2. A reported Lean formalization has not supplied the complete retained build and expert review needed to raise the rung. The checks here share arithmetic and construction primitives with the source |
| Stromquist’s printed 2003 argument fails: an exact open box of side fits the claimed container and avoids all twelve printed Figure 14 points | verified (exact-algebraic) |
It refutes the printed derivation, not the inequality, which the repaired cover independently certifies. Both this falsification and the adjacent repair are this project’s findings |
| Trump’s pose is locally isolated at fixed side: 128 branchwise linearized systems, each of exact rank 33 with a strictly positive exact stress | verified (exact-algebraic) |
Consequently, it is a strict local minimum of side in the anchored pose–side chart, modulo finite symmetries. This is not global optimality or an explicit isolation radius. Apparently novel here, not externally peer-reviewed |
| The one-dimensional class-angle optimum is a corner, with signed one-sided derivatives of about and per radian | numerically checked (numerical-f64) |
It is one slice. It is not a rigidity proof, and not a theorem that every derivative-free method fails. This project’s measurement |
The exact optimal configuration spaces at n = 3 and n = 4 |
verified (exact-algebraic) |
Only those two moduli spaces are classified here; the optimal side values at and are proved, but their optimal configuration spaces are not classified here. The labelled and unlabelled pieces agree with published computations; the rotation exclusion and full quotients are established here, with no novelty claim |
| In the retained early campaign, the same floating-point LP refiner takes the tested proved-control starts to the analytic optima (residuals ) and leaves the tested starts short | numerically checked (numerical-f64) |
The solver floor is about in the side, so read smaller residuals as “at the floor”; and it does not establish why the starts are far away |
Result claims and confirmation
T-060 establishes the eleven-square value at V3/C3. T-112 reads its equality case
to conclude uniqueness up to the container’s eight symmetries and relabeling, at
V3/C2; no new geometric computation is claimed.
Its confirmation level stays separate from T-060’s. The
uniqueness review
states the equality inference and its scope.
The source of the eleven-square Lean formalization reports a complete check, while the
retained local build covers the statement closure and upper half.
Its reported compiler-trusting native_decide facts and incomplete local replay do not
raise T-060’s rung.
At seventeen squares, T-153’s conditional candidate proof and T-154’s
separate Lean proof both remain V0/C1/S5. T-154 does not formalize T-153’s argument.
Its source reports a build of a theorem with no open certificate premise, trusting the
Lean compiler and native evaluator for 13,343 finite facts.
The project has read and sampled parts but has not reproduced the complete build.
The Lean packet and
candidate packet
keep those boundaries explicit.
Beyond these central cases, the admitted record contains construction and lower-bound
results. T-157 gives Guzhou0806’s strict at V3/C3, with the
continuous cover reproduced using the producer’s kernels.
T-158 gives Ostashev’s exact upper-bound constructions for 175, 232 and 264
squares at V3/C3, checked by repository implementations.
Their different claims require different proof objects: an exclusion of every packing
below a side in the first case, three valid constructions in the second.
The results register records the sources, deciding code,
credit and scope of each.
Open
1. How to identify terminal components. Point-basins are well-defined, but at an exact connected sliding family shows that they can split one connected terminal component into infinitely many endpoint keys. The store therefore counts endpoint keys, which may split one component into several rows, and the denominator of “rare” is not yet a number. This makes the rarity premise untestable rather than merely untested, which is a stronger objection than doubting it. Settling it takes Jacobian nullity, feasible tangent directions, and certified continuation. It is not a code change; it is the shape of the deliverable.
2. Whether record packings are rare under a named proposer. The cartography strategy rests on this, and it has never been measured, because it is a query over the census in (1). The kill criterion is written down: if record basins are hit at rates within about ten times the modal basin’s, the strategy stands down and the campaign reverts to throughput.
3. How reliably a named proposer reaches oblique records. The early screening campaign supplies two negative measurements: at five seeds land in a band five times narrower than the remaining gap, and at the annealer returns the trivial grid on every seed against a record of . Those failures concern the tested annealer, not every proposer or the external methods that have produced oblique constructions. A comparison needs a named method, controls, equal budgets and retained outcomes; the methods survey and current campaign record supply the implementation inventory.
4. A simpler proof of . T-060 settles at Trump’s side at V3/C3,
machine-checked with its review record pending; what stays open is a shorter argument,
the oversight record that lifts it to V4/C4, and completion and expert review of the
reported formalization sufficient for V5.
5. What a floating LP result means below . The floor comes from HiGHS’s
own feasibility tolerance—pinned at , the strictest value it accepts—under
which post-checked side residuals bottom out near , about five orders above
f64 machine epsilon: a property of the solver, not of the hardware.
Many rounds sit on it, and no comparison finer than the floor is admissible.
An exact LP over certified rational or algebraic coefficients would remove that
particular tolerance boundary; a purely rational LP applies only when the fixed-angle
cell has rational coefficients.
The early search pipeline does not supply this general replacement.
Exact solves elsewhere, including the regularizer, have their own scope.
6. Whether endpoint results reproduce across machines. Endpoint identity depends on floating-point behaviour in a degenerate linear program, and the same seed can reach a different endpoint under a different toolchain. Reproducibility checks therefore need to distinguish portable mathematical predicates from endpoint measurements tied to a particular toolchain.
7. Confirming the two reports that is Bidwell’s side. Two source packets
were published on 12 October 2026, by separate routes: Overbeck’s candidate
proof (T-153) and Fitzharding’s Lean 4 proof
(T-154). Reviews here read parts of both and found no
mathematical defect in what they read, but neither has been replayed in full, so both
stand at V0/C1 as reported results.
The verified bracket has the strict lower bound and the
rational upper bound
(case record). What is open is that replay: T-153’s capture
recomputation and ten of its thirteen trees, and a complete build of T-154’s Lean proof.
This project’s own route to a proof by the shape that settled , with its cover
and its local half proved and its global half and capture not, was suspended on 13
October, the owner judging it likely subsumed by Overbeck’s proof
(owner decisions).
§7 explains the machinery in general,
and the n = 17 explainer gives that
route’s numbers, records and status.
Items 1 and 2 decide whether the cartography strategy is sound. Items 3, 5, and 6 have concrete experimental or engineering paths. Item 4 is what remains at now that T-060 has determined : a shorter proof is mathematical work, not an engineering task whose tractability is established. Item 7 awaits the complete replays named in the register for each report.
9. Vocabulary
Every word below is used narrowly here, and each earns a row by being one a general
reader would otherwise read loosely.
Symbols are in §10, and SYNOPSIS.md is the
authority for everything it defines.
Several rows below are local to this document: the covering-LP terms introduced above,
terminal set, which the synopsis uses without defining, and feasibility
tolerance, which belongs to the solver rather than to the project.
The stationary-backbone terms are shared with the current exploration and agenda, but
they describe a proposed completeness object rather than a built global enumerator.
The rows from cap down belong to the optimality-proof machinery of
§7.
The order is by dependency, so it reads top to bottom.
Three words carry controlled multiple senses—cell, quench and exploration—and the rule for each is given with it.
| Term | Means |
|---|---|
| configuration | A placement of all squares plus the container: coordinates |
| cell | A choice of separating axis and order for every pair. Always the configuration-space object; write instance cell for a sweep position, event cell for a region of centres and cover cell for a region of the centre box, never bare “cell” for any of them |
| atom / weight | An exact point in a candidate container, and the nonnegative rational amount of bookkeeping mass assigned to it. An atom has no area and is not a packed square |
| atomic measure / mass | The rule assigning a region the sum of the weights of its atoms, boundary atoms included; the mass is what that rule returns |
| site / pose | A candidate atom location, and one square at one centre and angle. In the covering LP, sites are columns and poses are rows |
| direction net | The finite set of exact square orientations a certificate checks. A strict shrink condition lets a nearby net direction stand in for any orientation at all |
| event cell | One open region of admissible centres on which the set of atoms a square covers is constant. Not a configuration-space cell, and never written bare |
| weighted fractional unavoidable-set certificate | A finite weighted atom set whose total mass is below but whose mass is at least one in every prescribed inner square; with the direction and shrink conditions, that tension is a lower bound on |
| individual-side certificate / dilation-limit proof | An individual-side certificate instantiates one finite certificate at its named container side. A dilation-limit proof combines exact certificates at approaching sides with a density argument to prove the displayed . Both yield proved lower bounds; the terms distinguish proof constructions, not verification levels |
| core / trace / charge | A core is the shrunken closed square selected inside a physical unit square. Its trace on a finite site set is the subset of it contains. Its charge is the sum contributed by the point and threshold atoms it triggers |
| row generation / column generation | Adding a deficient square-pose constraint, or adding a candidate atom site. Rows restrict the cover; columns give it more choices |
| dual depth / pricing | The sum of dual pose weights covering one point, and the search for an absent site where that depth exceeds one |
| dual support / fractional packing | The held poses with positive dual weight, and their interpretation as weighted, possibly overlapping squares whose depth is capped at one at the held sites. It is not a physical packing |
| quench | A deterministic refinement map and, here, its cell-and-angle implementation. Its numerical stopping condition does not itself certify a local minimum; an unsettled run is exploratory data |
| basin / point-basin | The set of configurations one quench carries to a single returned pose. Defined relative to that quench, so a different refiner gives a different decomposition; too fine when one terminal component is a family |
| polish | Refinement within the basin you are in. This is what the quench does, and all it does |
| exploration | Reaching a different basin. Write packing exploration for this project directory and exploration report for an X-NNN artifact |
| polish failure / exploration failure | The two ways a search gap can decompose: a gap the refiner closes, versus one that survives it. Which one a number is cannot be read off the number |
| proposer / refiner | The two halves of the search loop—what emits candidates, and what improves them. Named apart because the measurement that matters is which is failing |
| terminal set | For the idealized mathematical decomposition, the local-optimal configurations. An implemented refiner returns numerical endpoints, whose membership needs certification |
| terminal component | A connected component of the mathematical terminal set, the intended atlas object; numerical endpoint keys do not certify it |
| terminal family | A terminal component that is not an isolated point |
| contact graph | One vertex per square and one edge per touching pair, optionally with wall vertices. It records incidence, not the feature or branch equation that realizes the contact |
| typed contact | A contact plus its corner, edge, or wall features; owner square and axis; separation order and sign; and chart data—the information needed to write one branch equation |
| support branch | One smooth piece of the disjunctive feasible set obtained by fixing a consistent typed separation for every square pair and a typed description for each wall row |
| active constraint / active set | A branch inequality that is tight, and the set of all such rows. The active set can be larger than the positive multiplier support |
| feature tie | A geometry where several support descriptions are simultaneously valid. Every applicable typed branch must be retained |
| Fritz–John stationarity | The first-order multiplier condition necessary at a constrained branch minimum. Satisfying it produces a stationary candidate, not a proof of minimality |
| normal (ordinary) Fritz–John branch / abnormal Fritz–John branch | The cases where the objective multiplier is respectively positive or zero. The normal case gives a KKT multiplier certificate. One geometry may admit both certificate types; only a proved constraint qualification lets an enumeration omit every abnormal branch |
| zero multiplier / positive multiplier support | A tight row with zero coefficient in one stationary certificate, and the smaller set of rows whose coefficients are positive. Neither is the complete contact set |
| rattler | A square or cluster with feasible local motion inside a cage while the remainder stays jammed. Its variables and inequalities remain part of global feasibility |
| typed stationary backbone | The proposed branch record containing all configuration variables and every typed pair and wall constraint, followed by its active subset, multiplier states and support, charts, symmetries, rattler attachments, and the continuous stationary equations they index |
| stationarity | Satisfaction of a necessary first-order condition on a declared branch. It does not by itself imply rigidity, local minimality, or global optimality |
| rigidity | No non-trivial feasible local motion, under a declared quotient. Contact counts are evidence for it, never a proof of it |
| corner / kink | A point where one-sided derivatives differ, so the derivative fails to exist rather than becoming large |
| angle class | A set of squares constrained to share one angle |
| descriptor | A structural coordinate of a packing—contacts, angle classes, symmetry—used to steer search toward diversity rather than toward loss |
| bound gap | The distance between the best-known upper and lower bounds for an ; a property of the problem |
| search gap | best_side − standing best, signed; a property of one run |
| standing best | The best side ever published for that —an upper bound, not known to be optimal in the open cases |
| feasibility tolerance | The margin by which HiGHS may let a returned solution violate its own constraints. Pinned at the strictest value it accepts, and the origin of the floor—a property of the solver, not of the hardware |
| assurance | reported, numerically-checked, or verified; method, actual precision, tolerance, and origin stay separate |
| atlas | The deduplicated store of endpoints for an . Code exists; it stores endpoint keys, which are not certified terminal components |
| census | An enumeration of an ’s basins run to saturation. Code exists; saturation is unreachable while the counted object is undefined |
| cap | A rational container side slightly above the known side, at which the global half of an optimality proof works. An exclusion at the cap holds at every smaller side; capture needs a cap so close to the known side that every packing it admits in the known state lies within the local radius |
| cover cell / capacity one | One closed region of a finite cover of the centre box, and the proved property that it holds at most one centre: by diameter below one for interior cells, by the depth-width wall lemma for wall and corner cells |
| occupancy state / orbit | The set of cover cells a packing’s centres name, one each, so an -subset of the cover; and a state together with its images under the container’s symmetries. Proving one representative proves the orbit |
| sub-pattern / forbidden | A set of cover cells, and the proved fact that that many squares cannot sit in them with disjoint interiors inside the cap container. A forbidden sub-pattern excludes every state containing it or any image of it |
| selector / prover / consumer | The heuristic that proposes sub-patterns and certifies nothing; the exact engine that certifies one; and the exact enumeration that removes the states a certified pattern excludes, as a set |
| flag / false flag | A sub-pattern the selector failed to place, reported with the best violation found rather than a margin; and such a pattern for which a placement exists. One false flag can remove half the census, which is why only the prover counts |
| owner / owned hull | A cover cell with one square in it, in the ownership-induction kernel; and the convex set of points proved to lie strictly inside that square in every pose that survives |
| angle row / residual / collision region | One closed interval of an owner’s orientation chart; the closed polygons holding every centre the owner can have at those angles; and the centres at which the owner would overlap a partner in every pose the partner can still take |
| closure / stall | A node ending with an owner that has no pose, or two owned hulls meeting; and a node that stops changing with poses left, a sound statement that these rows exclude nothing |
| Farkas closure | In the interval branch and bound, a node closed by a nonnegative multiplier combination of its rows that stays strictly positive on the whole box under outward rounding; the solver proposes the multipliers and the arithmetic certifies them |
| certificate / admission / ledger | A saved object a reader can check without the producer; the review that lets the census use it, after a fresh-process re-check, an independent verification and falsifier controls; and the file that records which certificates are admitted and which pending |
| falsifier control | A pattern that must not close, run through the same code at the same settings as a closure, such as the known packing’s own sub-patterns |
| slider / local minimum modulo sliders | A coordinate along which the known packing moves without changing its side; and the theorem that nothing within an explicit radius in the other coordinates is smaller, with the sliders left free in a box |
| ratio test | The first-order argument with a worst-case remainder: for every signed coordinate, a certified dual pushes a displaced packing back by its displacement while the curvature constants let the remainders push it out by at most a multiple of its square; a ratio below one forces zero displacement |
| capture / capture-target theorem | The step proving that every packing in the known state at the capture cap lies within the local radius of the family; and the composed local theorem it must reach, whose premises are the state and the radius |
| threshold atom | A finite site set S, a threshold k and weight w; it charges w to a core containing at least k sites and has budget w times the integer part of the site count divided by k across disjoint cores |
| regularization | A separately verified redraw of a credited arrangement, with exact side, identity and drawing admission recorded apart from any new bound |
| verification / confirmation | The evidence carried by a result’s source, and the verification established beyond its producing run, on the V and C scales |
| significance / novelty | A dated judgment of importance, and the origin or novelty assessment supported by the retained source search; neither substitutes for verification |
| contraction factor | The ratio of an owner’s residual extent after a round of kernel updates to its extent before. The rounds capture needs grow like the logarithm of the radius divided by the logarithm of this factor, so a factor near one is a stall, whatever the radius |
10. Notation
Symbols are grouped by topic. A subscript always picks out one square; a bare letter is the whole -vector. and index squares and indexes net directions; none of the three has a row below. and , which index the four corners of one square, get one because they appear inside .
| Symbol | Type | Means |
|---|---|---|
| integer | How many unit squares are being packed | |
| real | The optimal side: the smallest container that fits unit squares | |
| integer | A perfect-square root, in | |
| square | The candidate container a lower-bound certificate rules out | |
| positive rational | A candidate container side; in T-018 and in the cited ownership work | |
| , | point, nonnegative rational | An atom’s location and its weight |
| region | A region whose atomic mass is being measured, usually a closed side-B square |
|
| atomic measure | is the sum of over the atoms in | |
| , | finite sets | The held atom sites and held square poses in a covering LP |
| nonnegative real | The dual weight assigned to held pose | |
depth_y(x) |
nonnegative real | The sum of over held poses containing point ; pricing searches for an absent site where it exceeds one |
| positive rational | The shrunken square side in a certificate; in T-018 | |
| square | The closed side-B square placed strictly inside packed unit square |
|
| , | rational, angle | A net direction’s half-angle tangent and the direction itself: |
| angle | The difference between a square’s reduced orientation and the nearest net direction | |
| nonnegative rational | The largest tangent of a half-gap between adjacent net directions | |
| , | integer | Corner indices, , as in and |
| real, variable | The container side being minimised. Distinct from , which is the answer; is what the program solves for | |
| per square | The centre of square | |
| , | each | All centre coordinates |
| The angle of square | ||
| The angle vector —all angles at once | ||
| matrix | Rotation by | |
| Corner offset: corner of square sits at . Constant once is fixed. and are its components | ||
| unit | A separating axis; is the one a cell assigns to the pair | |
| integer | The number of unordered pairs of squares | |
| real | The angle shared by one angle class; at , the tilt of Trump’s five-square block | |
| real | The value of minimising | |
| The optimal side of a fixed cell as a function of its one free class angle | ||
| real | The standing-best side for an , used as the base of an inflation ladder . Known to equal in settled cases; in an open case it need not be a minimizer | |
| real | The slider parameter of the terminal family | |
| space | All packings of three unit squares in the side-2 container—the complete optimum space | |
| , | groups | The six relabellings of three squares, and the eight symmetries of the square container |
| The family’s coordinate after both quotients: | ||
| algebraic | A primitive element: the single number generating a packing’s field | |
| polynomial | The minimal polynomial of ; is the field’s degree | |
| element of | An arbitrary field element, represented by a polynomial in of degree | |
| algebraic | The primitive element for Trump’s packing, , of degree 8 | |
| The support-branch configuration vector collecting and every square’s centre and angle | ||
| real-valued function | Clearance in support-branch row ; feasibility is and the row is active when | |
| nonnegative real | The objective multiplier in the tutorial’s Fritz–John equation | |
| nonnegative real | The multiplier on branch constraint in that equation | |
| real | Slack in a container-inflation ladder | |
| real | The exponent in the superdisk family ; is a circle and approaches a square | |
| , | exact sides | The witness side and regularized-view side in §4; U there denotes the case’s verified upper bound |
| , | positive rationals | The exclusion cap, a rational side just above the known one, and the capture cap, closer still |
| real-valued function | The depth-width wall lemma’s bound on the separating gap of two squares with centres in a wall cell, for the separating normal ; the cell has capacity one when | |
| , | positive rationals | In §7 only: a wall cell’s depth from the wall and width along it |
| integer | In §7 only: the arity of a sub-pattern, its number of cells | |
| positive rational | A local theorem’s radius: how far, in each non-slider coordinate, its conclusion reaches from the known packing | |
| positive real | The contraction factor of one round of capture |
Two collisions are worth naming because they come from outside this document. Smale’s α-theory, in §3, has nothing to do with the primitive element . And the neighbouring research reports use for what this document calls , and for a per-square half-angle parameter rather than a single primitive element. Two more come from the optimality records, which this document follows in §7 alone: there is a contraction factor rather than a clearance function , and and are a wall cell’s depth and width rather than an angular error and an atom’s weight.
Part II of the series, the review of Overbeck’s , defines a few symbols of its own, which are local to it: the parent side , the least charge of an assigned core, the total budget , and a row , an interval of parent half-angle tangents with its core’s direction and side . Its is the shrunken side above, one for each row; its and are a row’s ends, not the angle-class angle of this card.
11. Further Reading
The concepts this document leans on, and where to learn each properly. Nothing here is required to follow the argument; it is what to read when a step feels asserted rather than explained.
Linear programming (§1). Any standard treatment—Chvátal’s Linear Programming, or Boyd and Vandenberghe’s Convex Optimization for the wider setting. What matters here is the geometry of the feasible polyhedron, the notion of a basis and of degeneracy, and duality; §2’s mechanism is a change of optimal basis and is hard to read without it.
Real algebraic number fields (§3). Cohen’s A Course in Computational Algebraic Number Theory covers primitive elements, minimal polynomials, and real root isolation. The primitive element theorem itself is in any graduate algebra text.
Certified and interval numerics (§3). Moore, Kearfott and Cloud’s Introduction to Interval Analysis for the arithmetic; Rump’s surveys for interval-Newton and Krawczyk; Smale’s α-theory for the existence-and-uniqueness style of certificate the same section mentions.
Symbolic elimination (§3). Cox, Little and O'Shea's Ideals, Varieties, and Algorithms for Gröbner bases, lexicographic order, and resultants—the tools that turn a contact system into a minimal polynomial.
Real semialgebraic geometry (§3). Bochnak, Coste and Roy’s Real Algebraic Geometry, or Basu, Pollack and Roy’s Algorithms in Real Algebraic Geometry, for the Tarski–Seidenberg theorem and quantifier elimination over the reals—the results behind “the optimal side is algebraic”.
Integer relation (§3). The PSLQ and LLL algorithms, and specifically what they do and do not prove: they find a relation, which is evidence, and never a proof that the relation is exact.
Optimality conditions (§3). Lagrange multipliers in the classical case, Fritz–John and KKT for inequalities. Fritz–John retains an objective multiplier and remains necessary without the regularity assumptions KKT needs; a constraint qualification is what permits the abnormal zero-objective-multiplier branch to be discarded. The rank condition supplies the missing equations in determinant form, but it is only a necessary condition.
Rigidity and jamming (§3). Connelly–Whiteley on second-order rigidity and Donev et al. on jamming, stresses, and rattlers provide the method language collected in the archive’s rigidity sources. They are analogues whose hypotheses must be re-established for rotating squares and their nonsmooth feature ties, not imported theorems about .
Energy landscapes (§5). Stillinger and Weber’s inherent-structure decomposition, which the quench map is borrowed from; and Doye, Miller and Wales on the 38-atom Lennard-Jones cluster, the double-funnel precedent the rarity premise rests on.
Group actions and Burnside’s lemma (§7). Any introductory text on finite groups or enumerative combinatorics; what is counted here is occupancy states up to the container’s symmetries, and the lemma is why the count is not the state count divided by the group’s order.
Branch and bound with certified pruning (§7). Neumaier’s survey Complete Search in Continuous Global Optimization and Constraint Satisfaction for the general method, and Farkas’s lemma in any linear programming text for why a nonnegative combination of valid rows that stays positive proves a box empty. The interval sources above supply the outward rounding.
The problem’s own literature. Every source below is archived locally under
resources/ and is greppable, with two exceptions: the
two record constructions survive through the archived survey and record-table captures
rather than papers of their own.
Trump’s 1979 packing is documented there and by this directory’s exact certificate; his
2023 author writeup is retained with a faithful extraction, which the archive README
records, while the original 1979 communication is not, and Bidwell’s 1998 record
likewise has no retained first-party document:
- Stromquist (2003), Packing 10 or 11 Unit Squares in a Square—the proof, the
lower-bound value, and the /
45°class bound - Trump (1979), the construction that is still the standing upper bound
- Friedman, Packing Unit Squares in Squares: A Survey and New Results (DS7)—the survey the frontier corpus is checked against
- Erdős and Graham (1975), the asymptotic waste line of work
- Nagamochi (2005), historical general lower bounds. The later counterexample to Lemma 1 and Karakuş’s replacement proof must accompany their use; T-083 to T-085 record the scopes.
- Karakuş (2026), the rectangle bound and the independent argument for for , registered as T-084
- Bidwell (1998), the record, the nearest genuinely oblique one
- Montanher et al. (2018), a rigorous computer-assisted optimality proof for rotatable unit squares in a container—three squares in a circle—and, until T-060 proved , the only one this project knew of
- Martin (2000), the compactness results behind “the infimum is attained”
- Dewar (2024), direction-typed contact graphs for homothetic oriented squares—useful combinatorial method evidence, not a completeness theorem for the global search
What does the arithmetic here
The exact algebra does not require a computer algebra system. An optional system is used only to rederive one constant.
- Exact arithmetic is hand-rolled and standard library only. Elements are polynomials with exact rational coefficients reduced modulo the minimal polynomial; equality is a zero-representative test and sign is rational-interval bisection. No floating point appears in either decision.
- A computer algebra system is optional, used in one place to rederive a constant the verifier already carries.
- The linear programs go through HiGHS, called from SciPy, whose feasibility tolerance is the origin of the floor discussed in §8.
- The screening annealer is compiled, for the reasons in §3’s cost table.
- External proof-assistant developments. The retained eleven-square Lean packet and seventeen-square Lean packet state what was reported, read and built here. They are not evidence that the complete formal proofs were replayed here.
12. Research and Implementation Guides
| If you want | Read |
|---|---|
| the state of the program, and every result with its status | SYNOPSIS.md |
| the two reported proofs of and what each still waits on | The n = 17 case record |
| this project’s own route to an optimality proof, suspended on 13 October 2026, with its numbers, records and status | The n = 17 explainer |
| what is in the directory and how to run it | README.md |
| every rule the directory runs on, and which are machine-checked | conventions.md |
| the mutable size-by-size experiment priority queue | Basin confidence ladder |
| what has gone wrong and what now stops it recurring | defects.md |
| the mathematics of in depth | Packing 11 Unit Squares |
| the whole story before T-060, from what a proof must do to what was left | n = 11, End to End |
| how record packings are constructed, searched, refined and certified | How Record Square Packings Are Found |
| implementation methods and solver tooling | Algorithms and Tooling |
| why pointing should beat scaling | A Search Philosophy |
| what is known for every | frontier/ |